
No products added!

In the fast-moving world of embodied AI research, a reliable, fully open-source robot arm is often the missing piece between validating an algorithm and shipping a real engineering result.
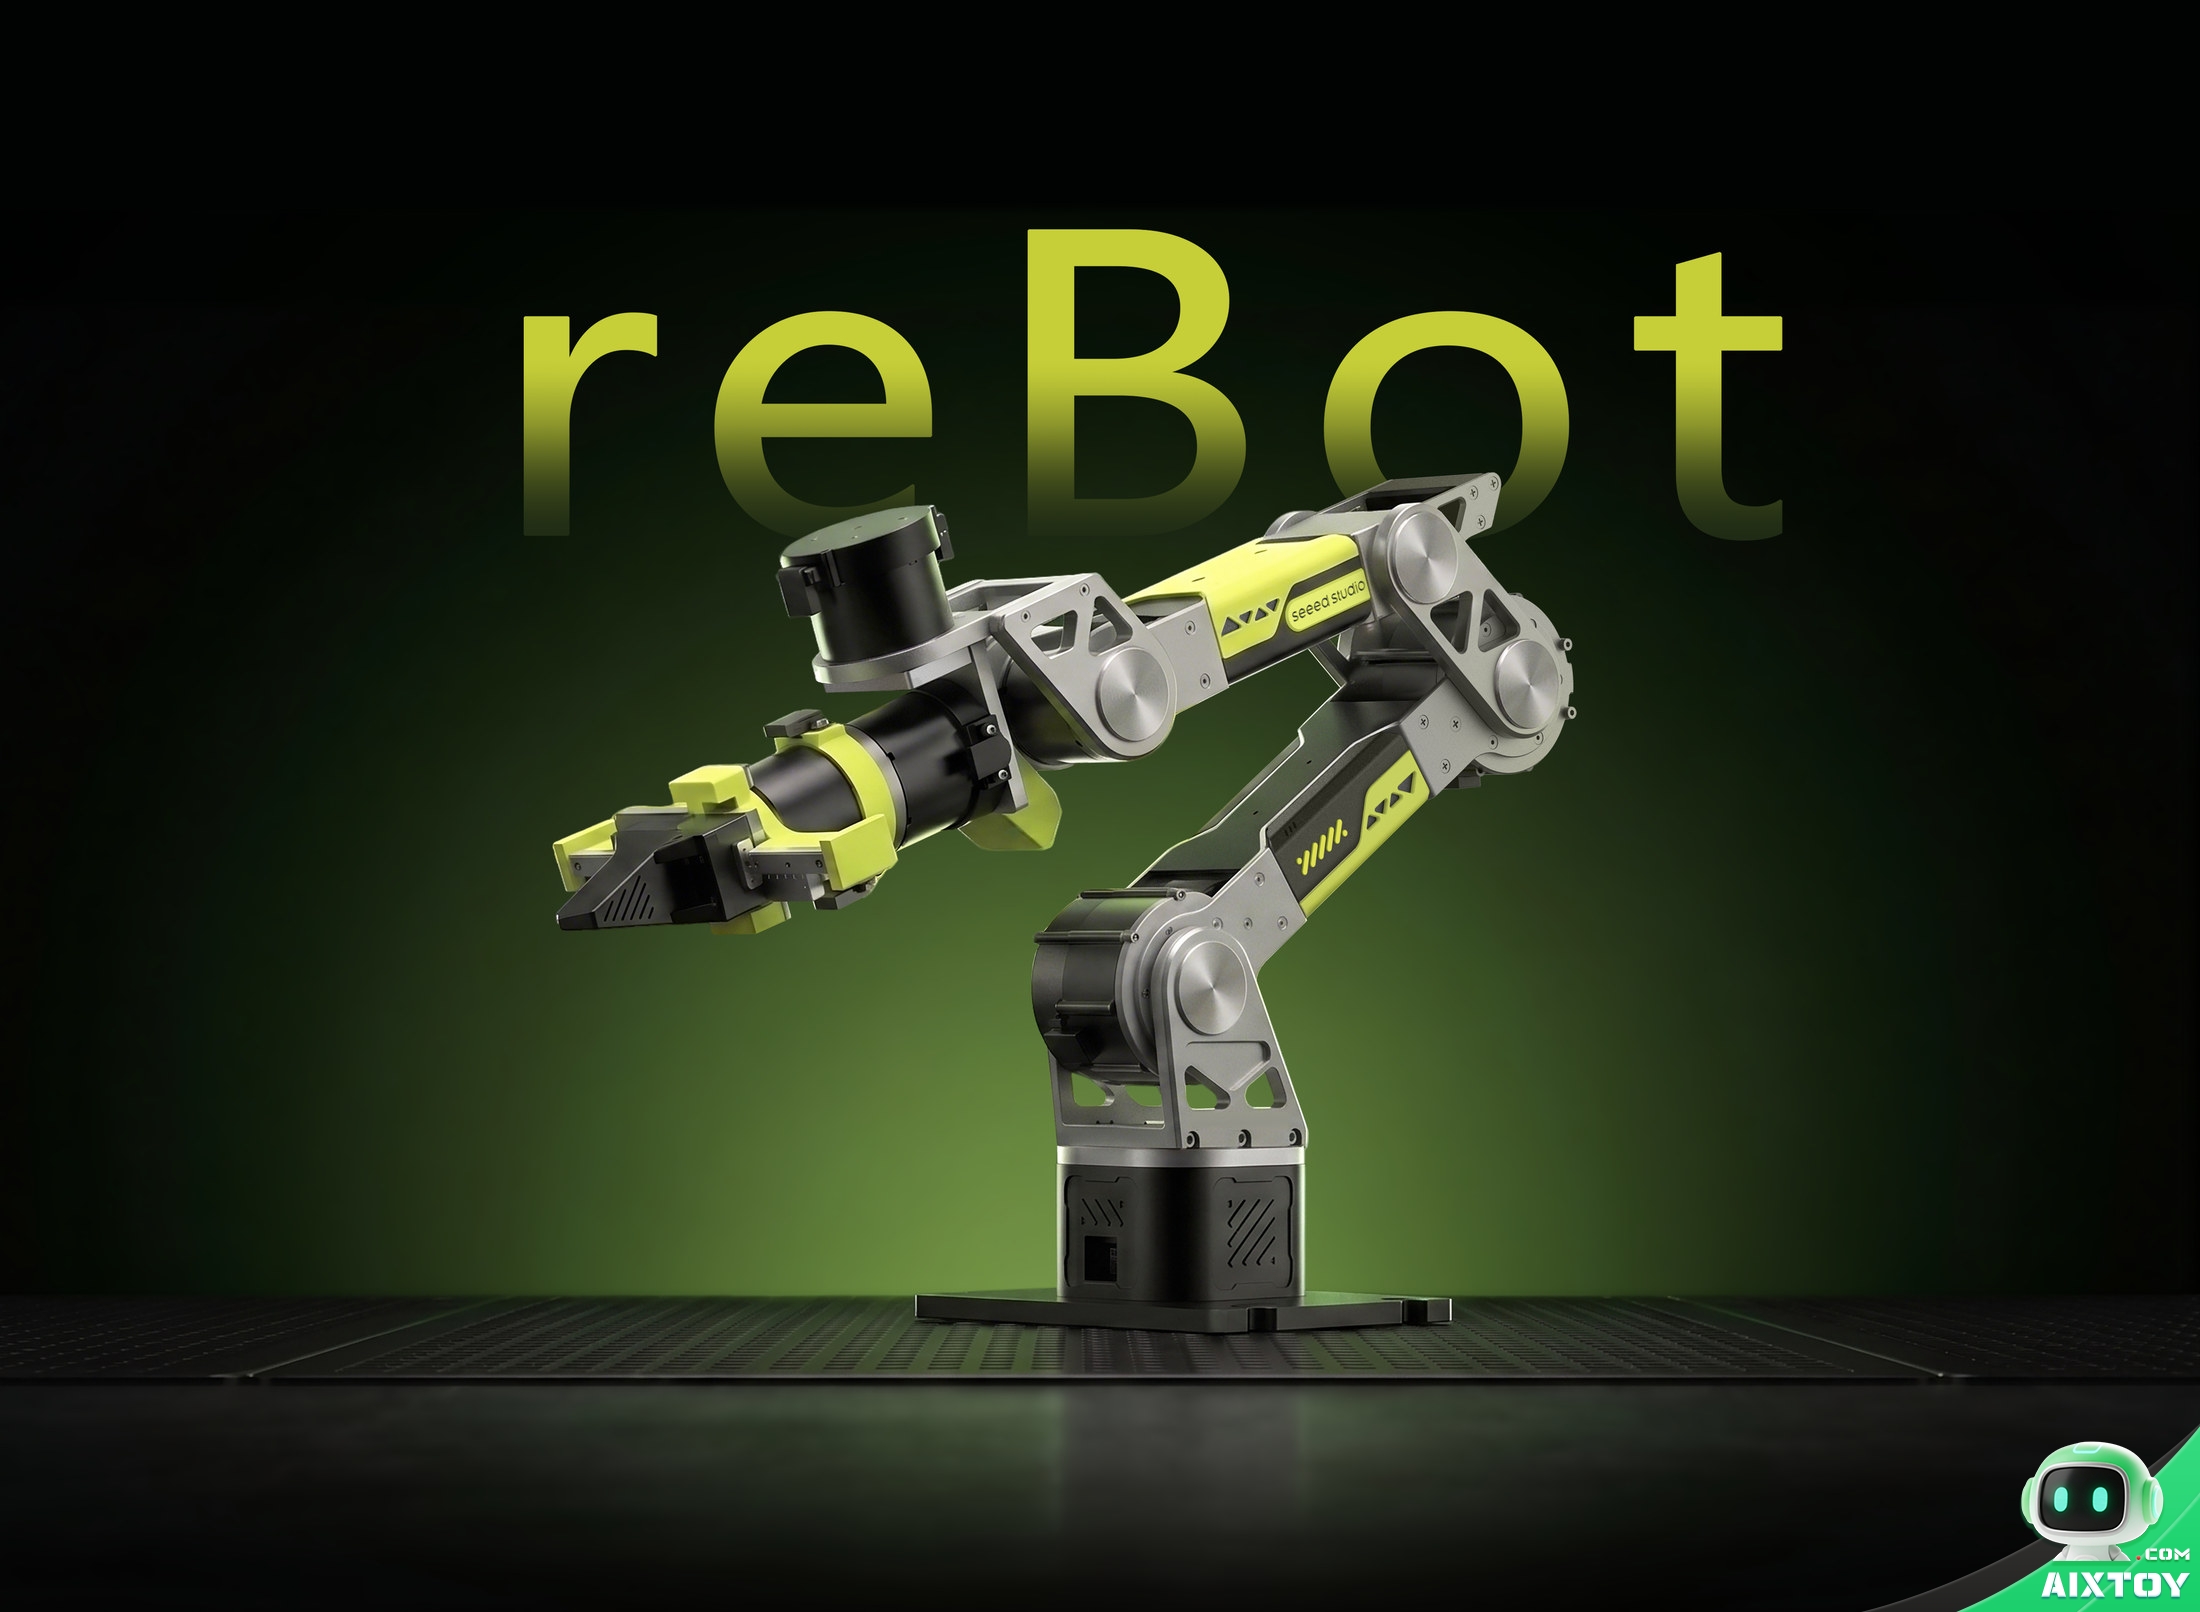
That is exactly what Seeed Studio’s reBot DevArm is built for. It is not just a pile of demo code — it is a complete open-hardware “main repository” that spans everything from mechanical CAD to the algorithm ecosystem, so a developer can genuinely replicate a six-axis robot arm from zero.
What “truly open source” actually opens up
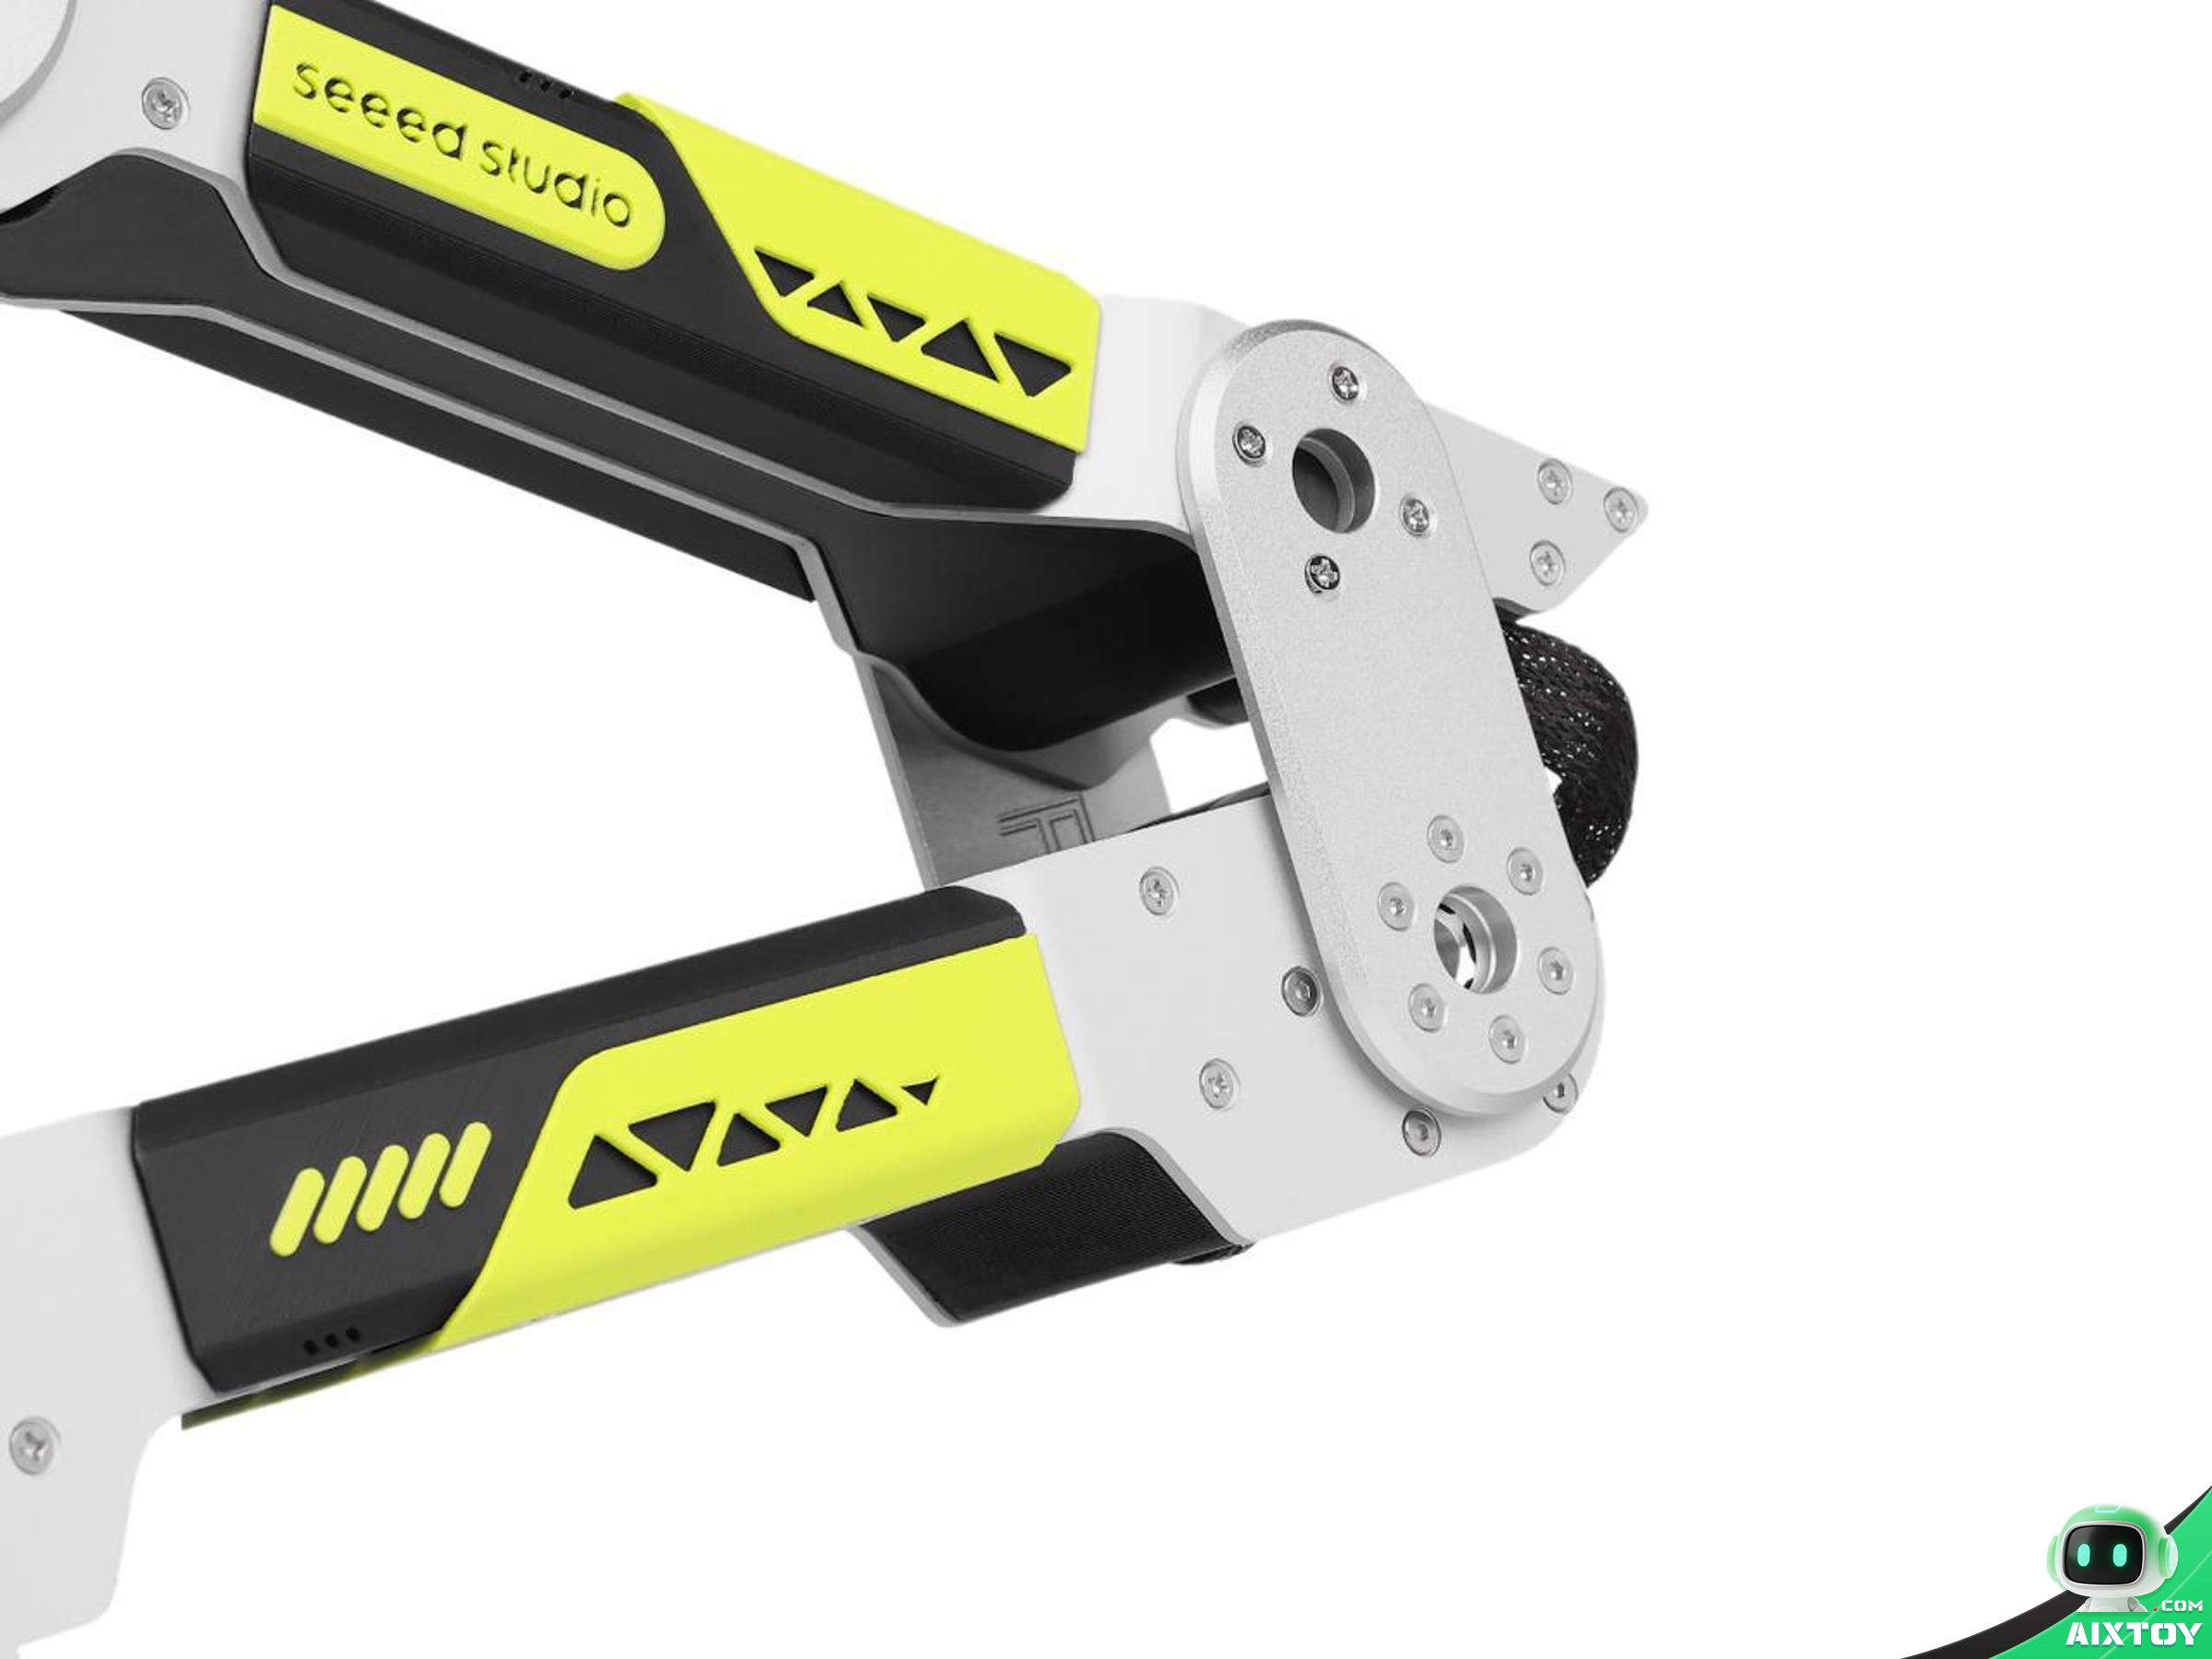
A lot of projects call themselves “open source” but only release firmware and sample code. reBot DevArm takes a different path: the hardware blueprints, the BOM, the mechanical source files, and the algorithm stack are all public.
Inside the GitHub repository’s hardware/ directory there are roughly 275 files, including 93 STEP files and 10 STP files. The reBot_Arm_description/ directory additionally ships self-contained URDF/STL packages for the DM and RS variants. The BOM drills down to the specification and purchase link of every single screw, and even lists reference prices for 3D-printed parts versus metal parts.
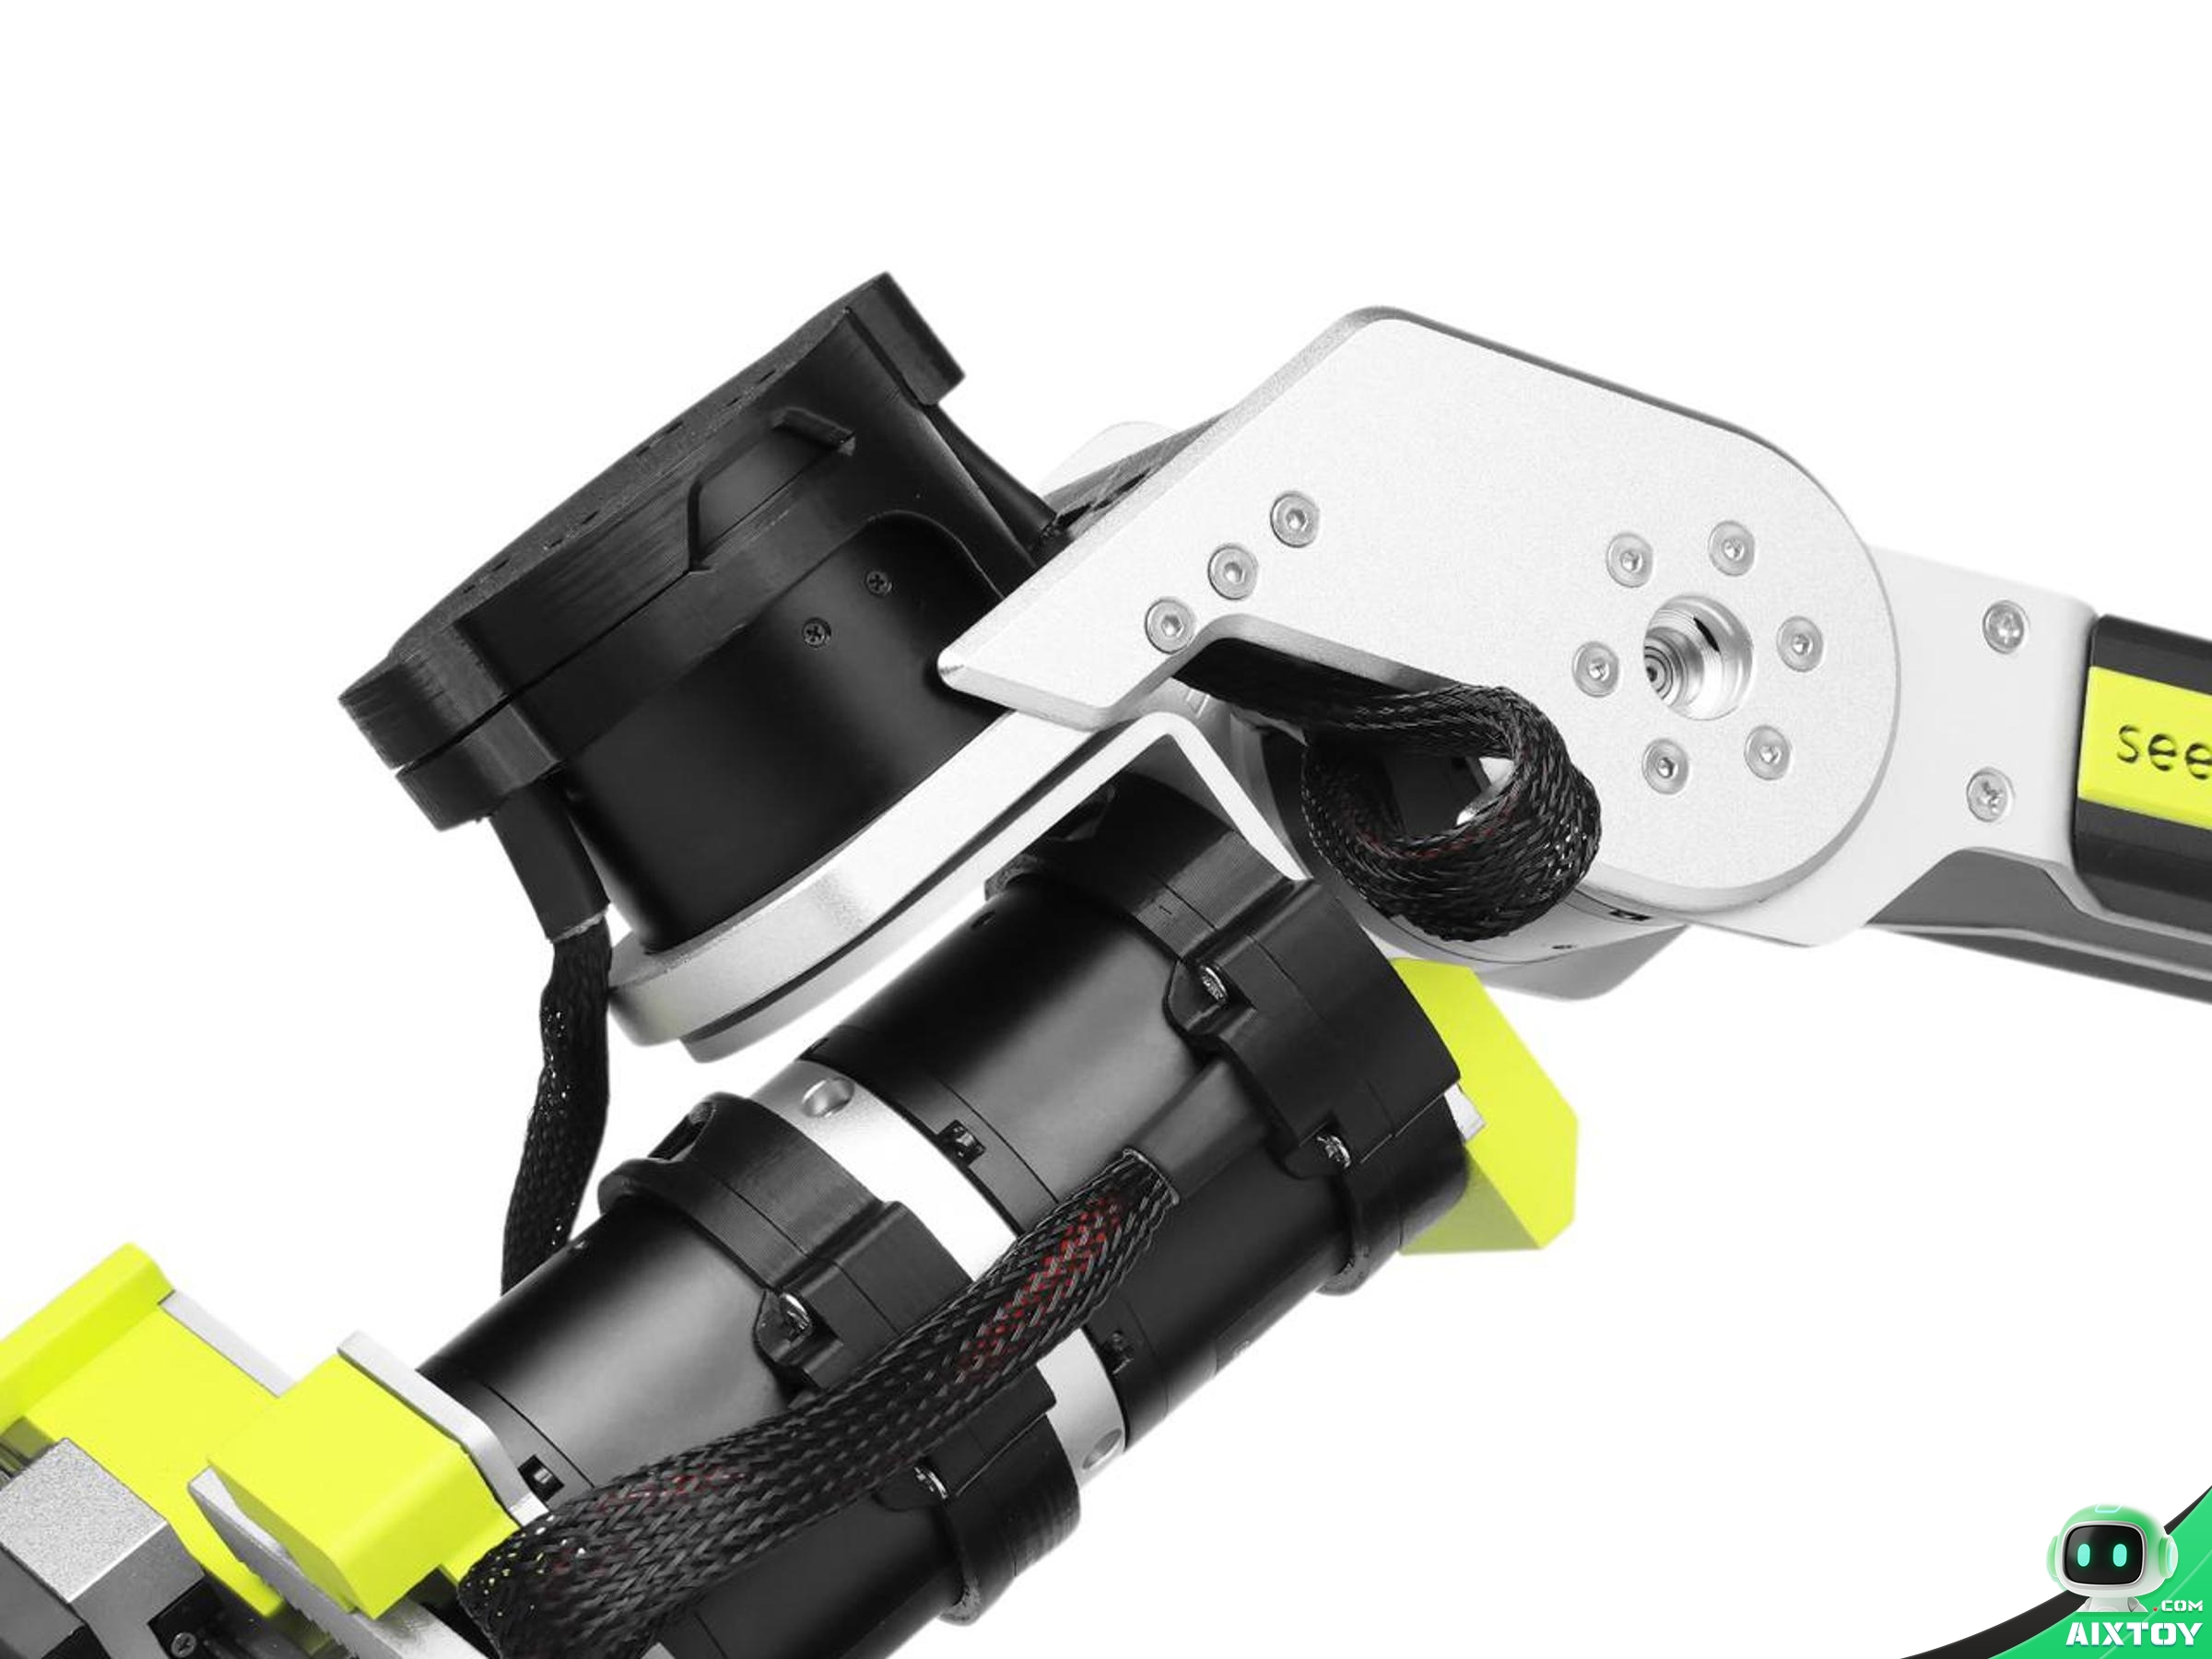
More importantly, these files evolve alongside the real hardware. The B601-DM v1.1 hardware revision added cable-strain relief at the end-effector joint, corrected the first-joint motor from the 4310 to the 4340P, and added a base stiffener. That tells you the published files are continuously updated from real assembly feedback — not a one-off marketing attachment.
Two versions: how to choose
reBot DevArm ships in two flavors, B601-DM (DaMiao motors) and B601-RS (RobStride motors). They look and feel similar, but the actuators and capabilities differ:
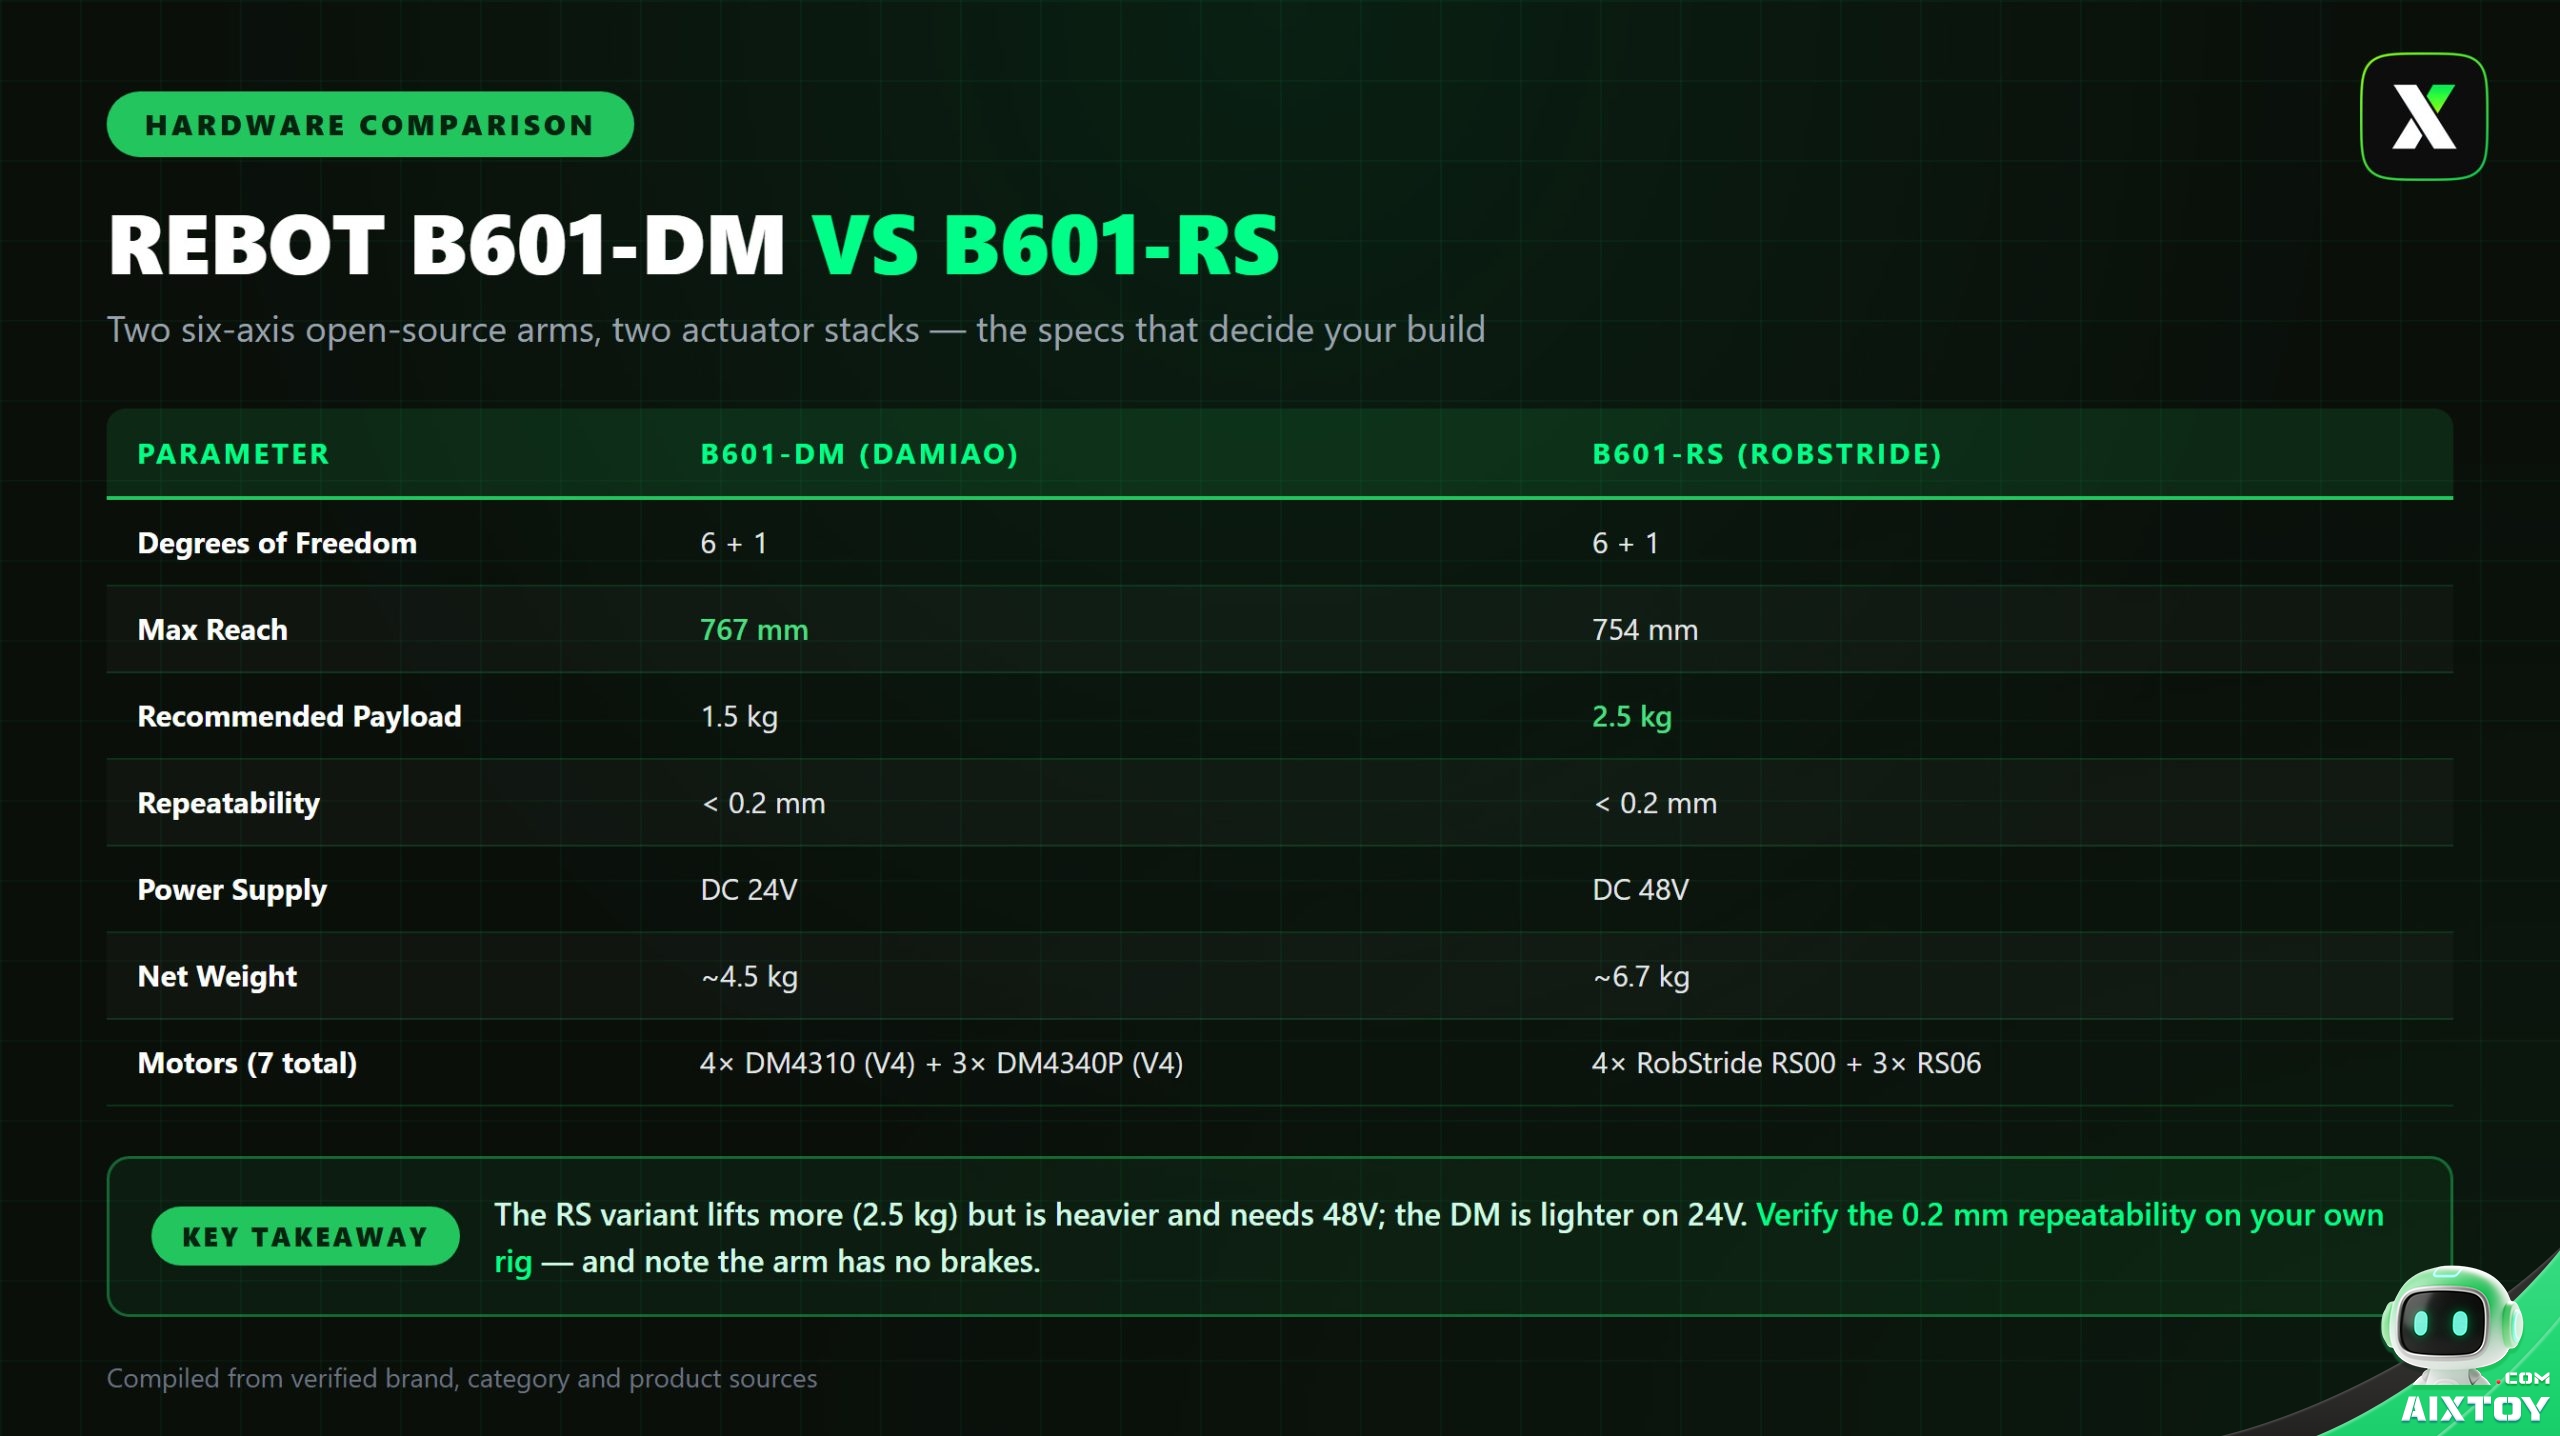
| Parameter | B601-DM | B601-RS |
|---|---|---|
| Degrees of freedom | 6+1 | 6+1 |
| Max reach | 767 mm | 754 mm |
| Recommended payload | 1.5 kg | 2.5 kg |
| Repeatability | < 0.2 mm | < 0.2 mm |
| Power supply | DC 24V | DC 48V |
| Net weight | ~4.5 kg | ~6.7 kg |
- The B601-DM uses four DM4310 (V4) and three DM4340P (V4) motors; the B601-RS uses four RobStride RS00 and three RS06. The seventh motor drives the gripper.
- The community treats the 0.2 mm repeatability figure with some skepticism — plan to verify it on your own rig.
- The arm has no brakes, so it is not recommended for carrying objects that must never be dropped.
From Quest 3 to the real machine: a complete VLA pipeline
The most instructive part of reBot DevArm is how deeply it plugs into the NVIDIA and Hugging Face embodied-AI stack.
In July 2026, NVIDIA natively integrated Isaac Teleop (its teleoperation data-collection tool) and GR00T N1.7 (a 3-billion-parameter, Apache-2.0-licensed open VLA foundation model) into Hugging Face LeRobot. Seeed’s reBot DevArm (7 DoF) successfully adapted to every layer of that stack, becoming one of the first physical hardware platforms for this new paradigm.
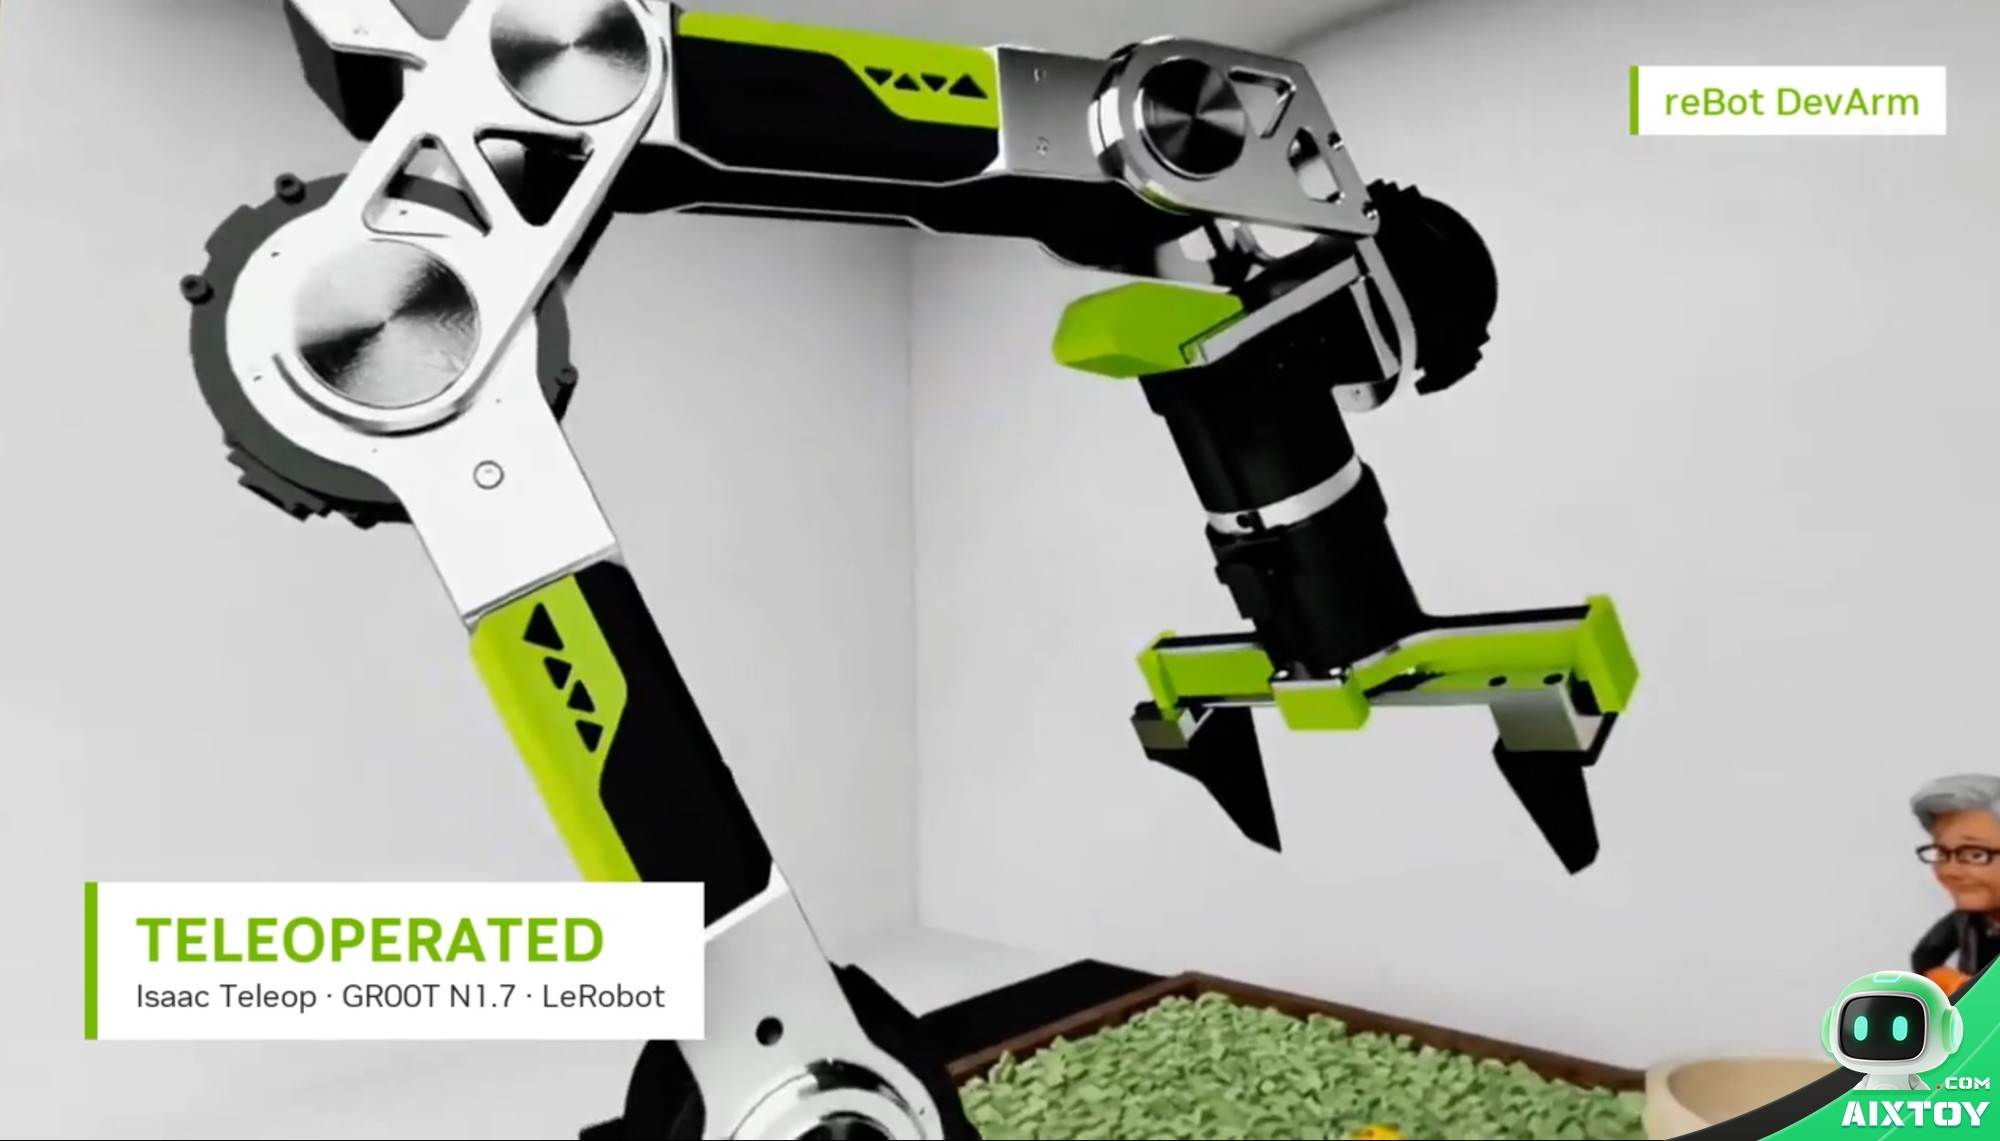
NVIDIA senior developer advocate Asier Arranz documented the full loop in a real validation run: teleoperating a reBot DevArm in Isaac Lab with a Quest 3 headset, collecting 40 demonstrations, packaging them as a standard LeRobot dataset, and fine-tuning GR00T N1.7 — by the next morning the arm could complete the task autonomously, with the entire learning loop running in simulation.
That means a developer can now go from “teleoperate → collect data → train in simulation → deploy on hardware” in roughly a single night, using just a VR headset and a reBot DevArm.
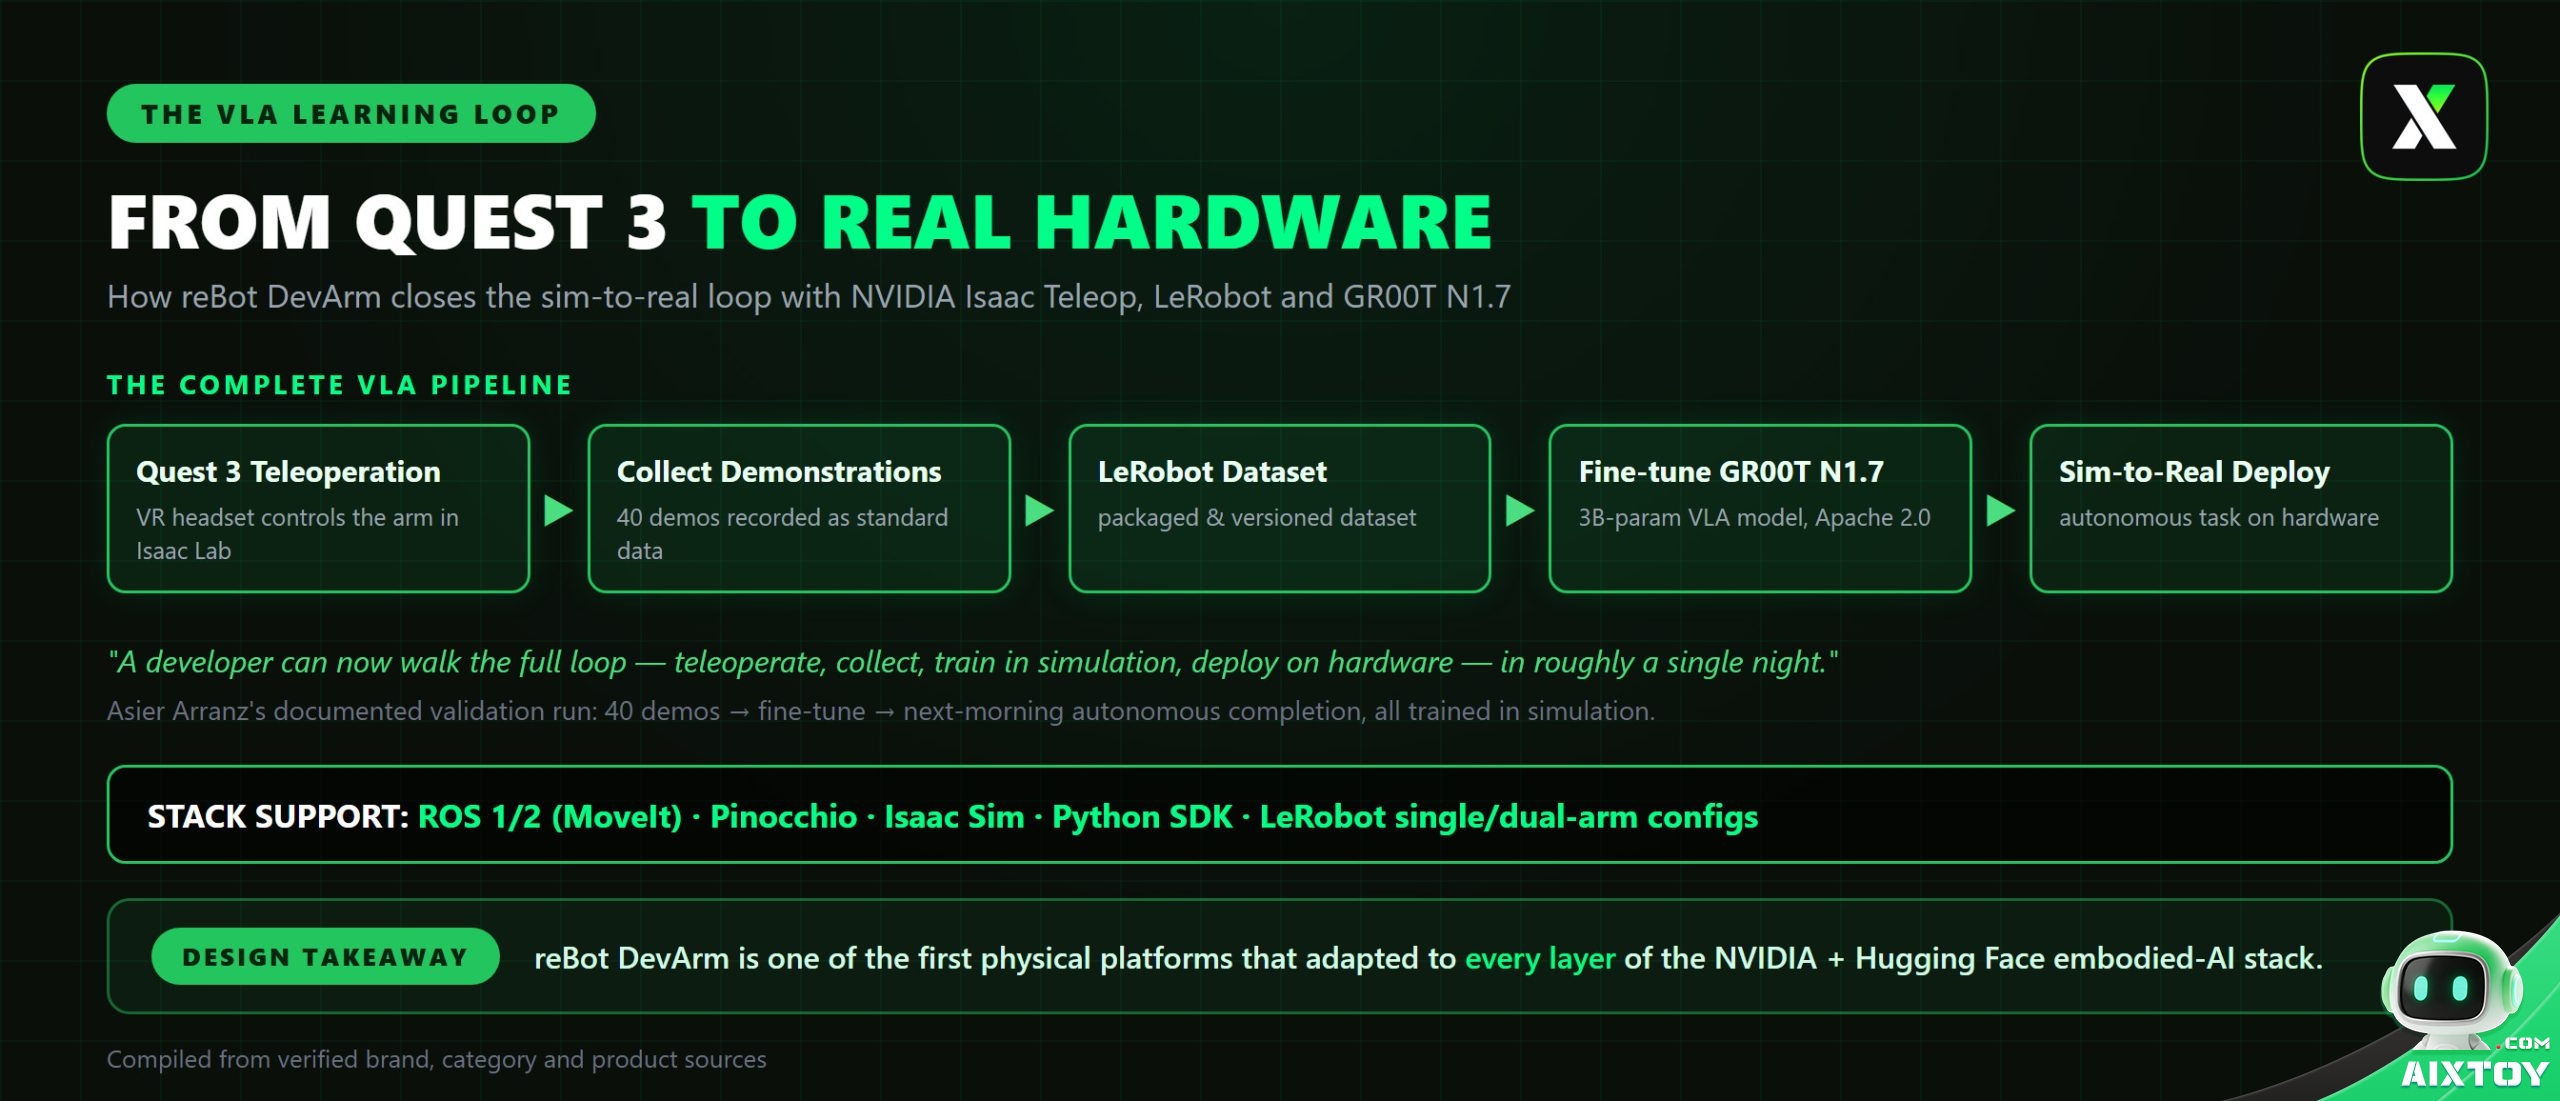
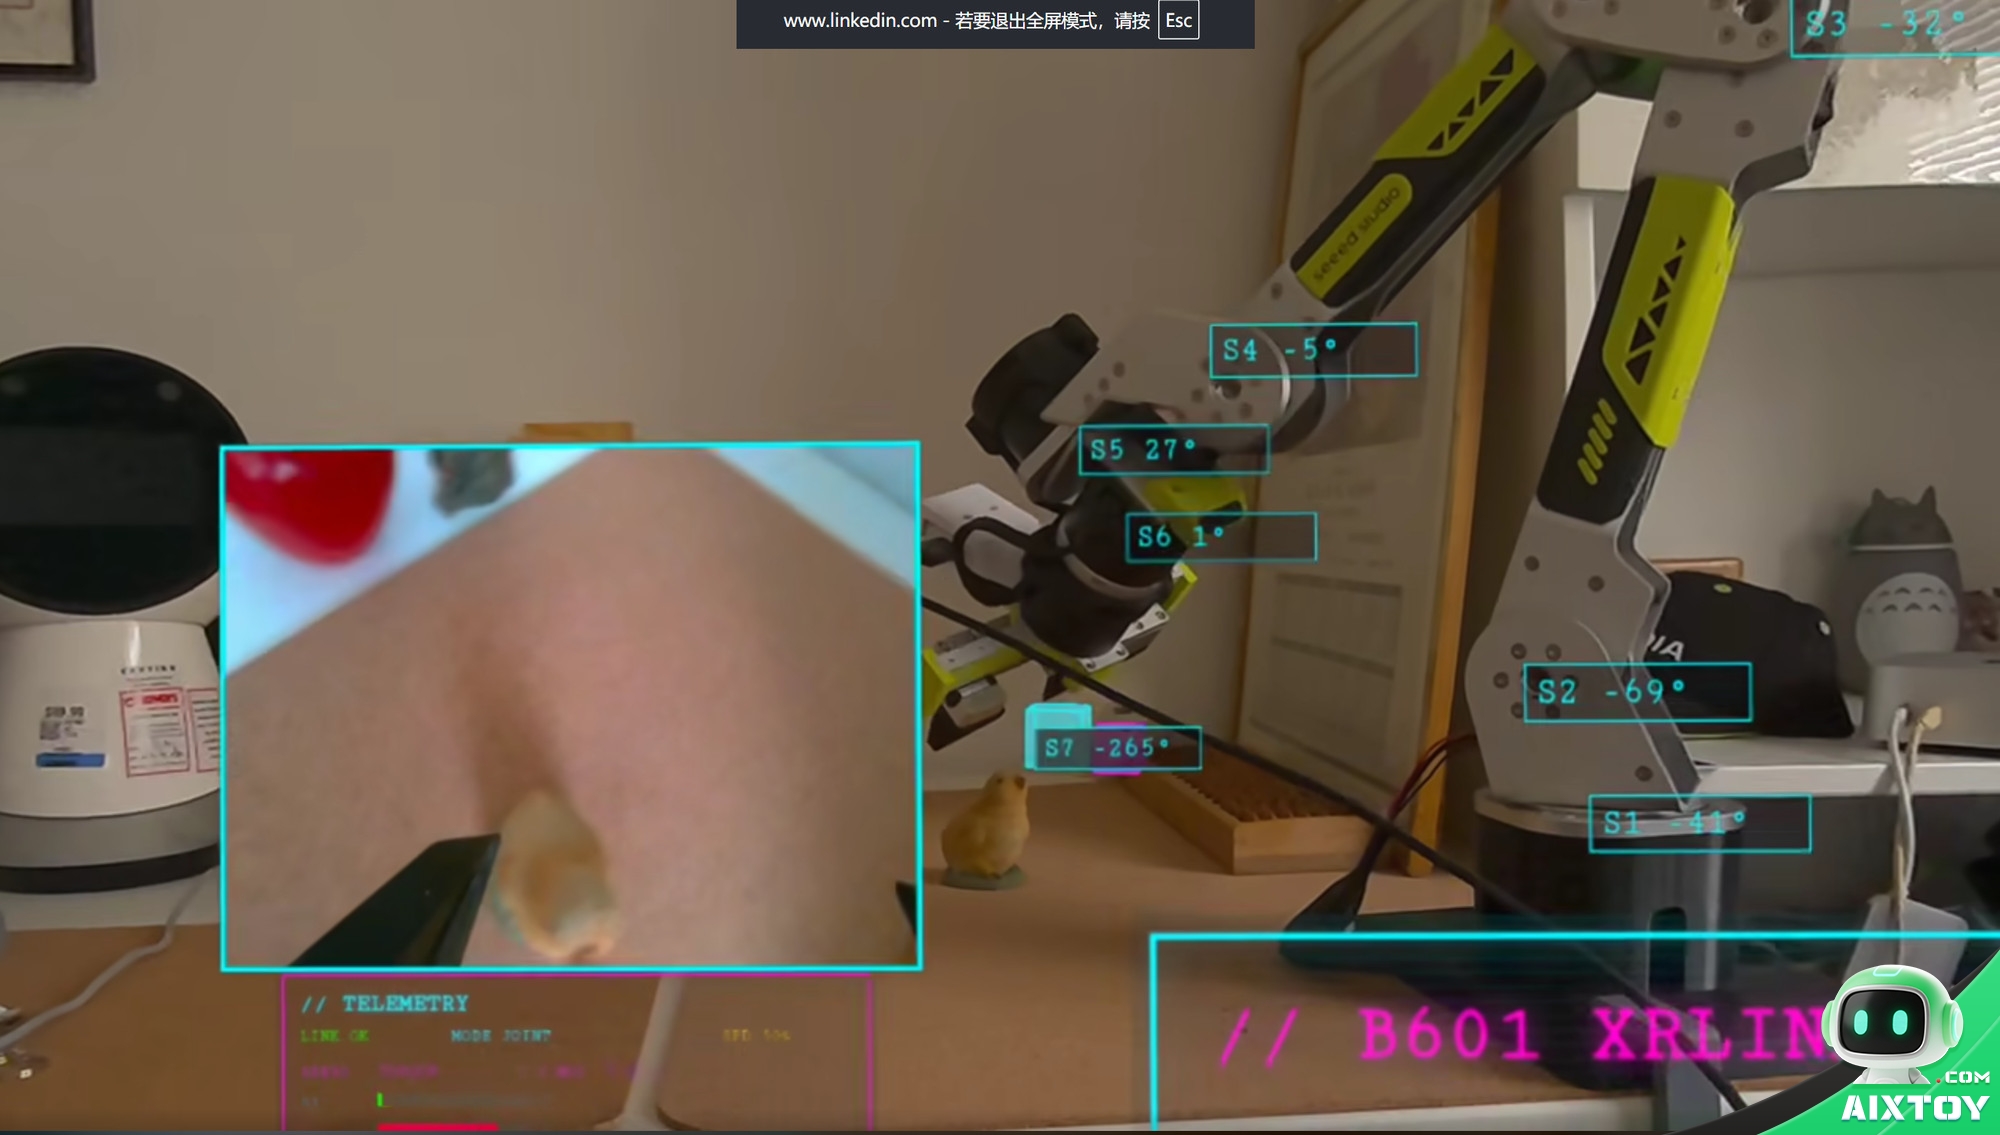
Beyond that, the arm supports ROS 1/2 (including MoveIt), Pinocchio, Isaac Sim, and a Python SDK. The official LeRobot docs have also registered single-arm and dual-arm configurations for the reBot B601.
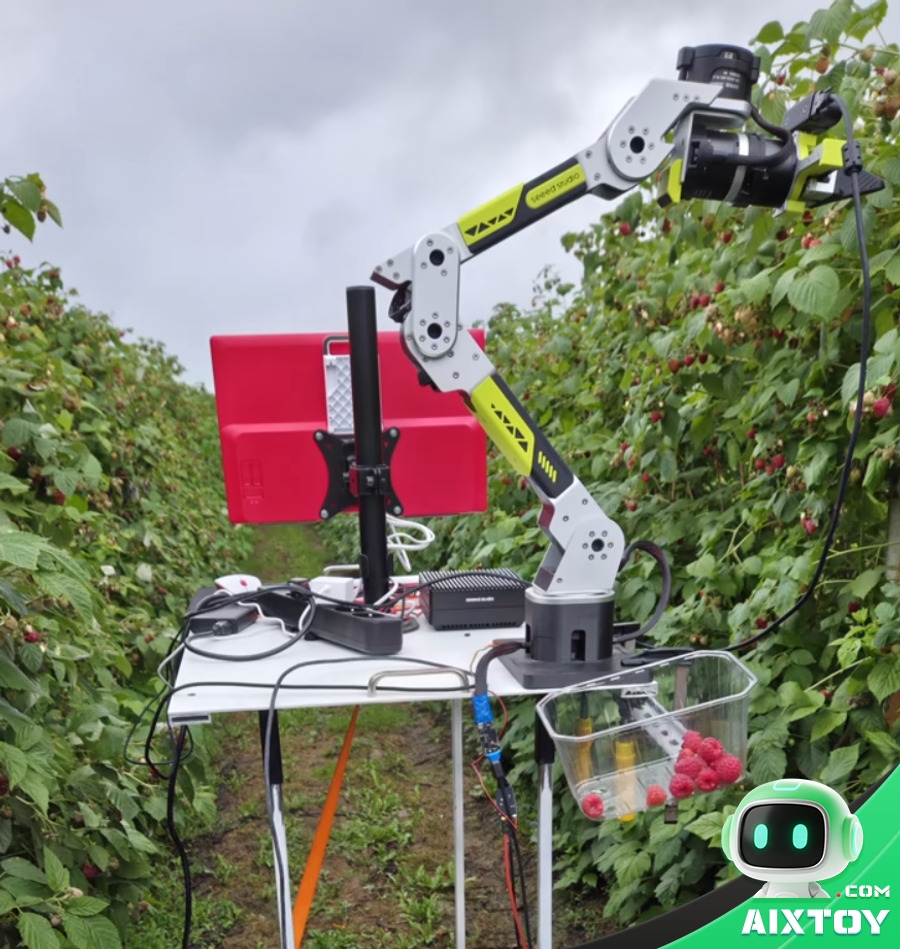
Kit options and replication cost
Seeed offers five kit configurations, from a bare motor kit all the way to a fully assembled unit, so you can pick the level of DIY that fits:
| Option | What it includes |
|---|---|
| Arm Body — Motor Kit | Motors and wiring only |
| Arm Body — Structural Kit | Mechanical structural parts only |
| Gripper — Complete Kit | The complete gripper kit |
| Full Kit | Arm body + gripper, complete kit |
| Pre-assembled Robotic Arm | Fully assembled finished unit |
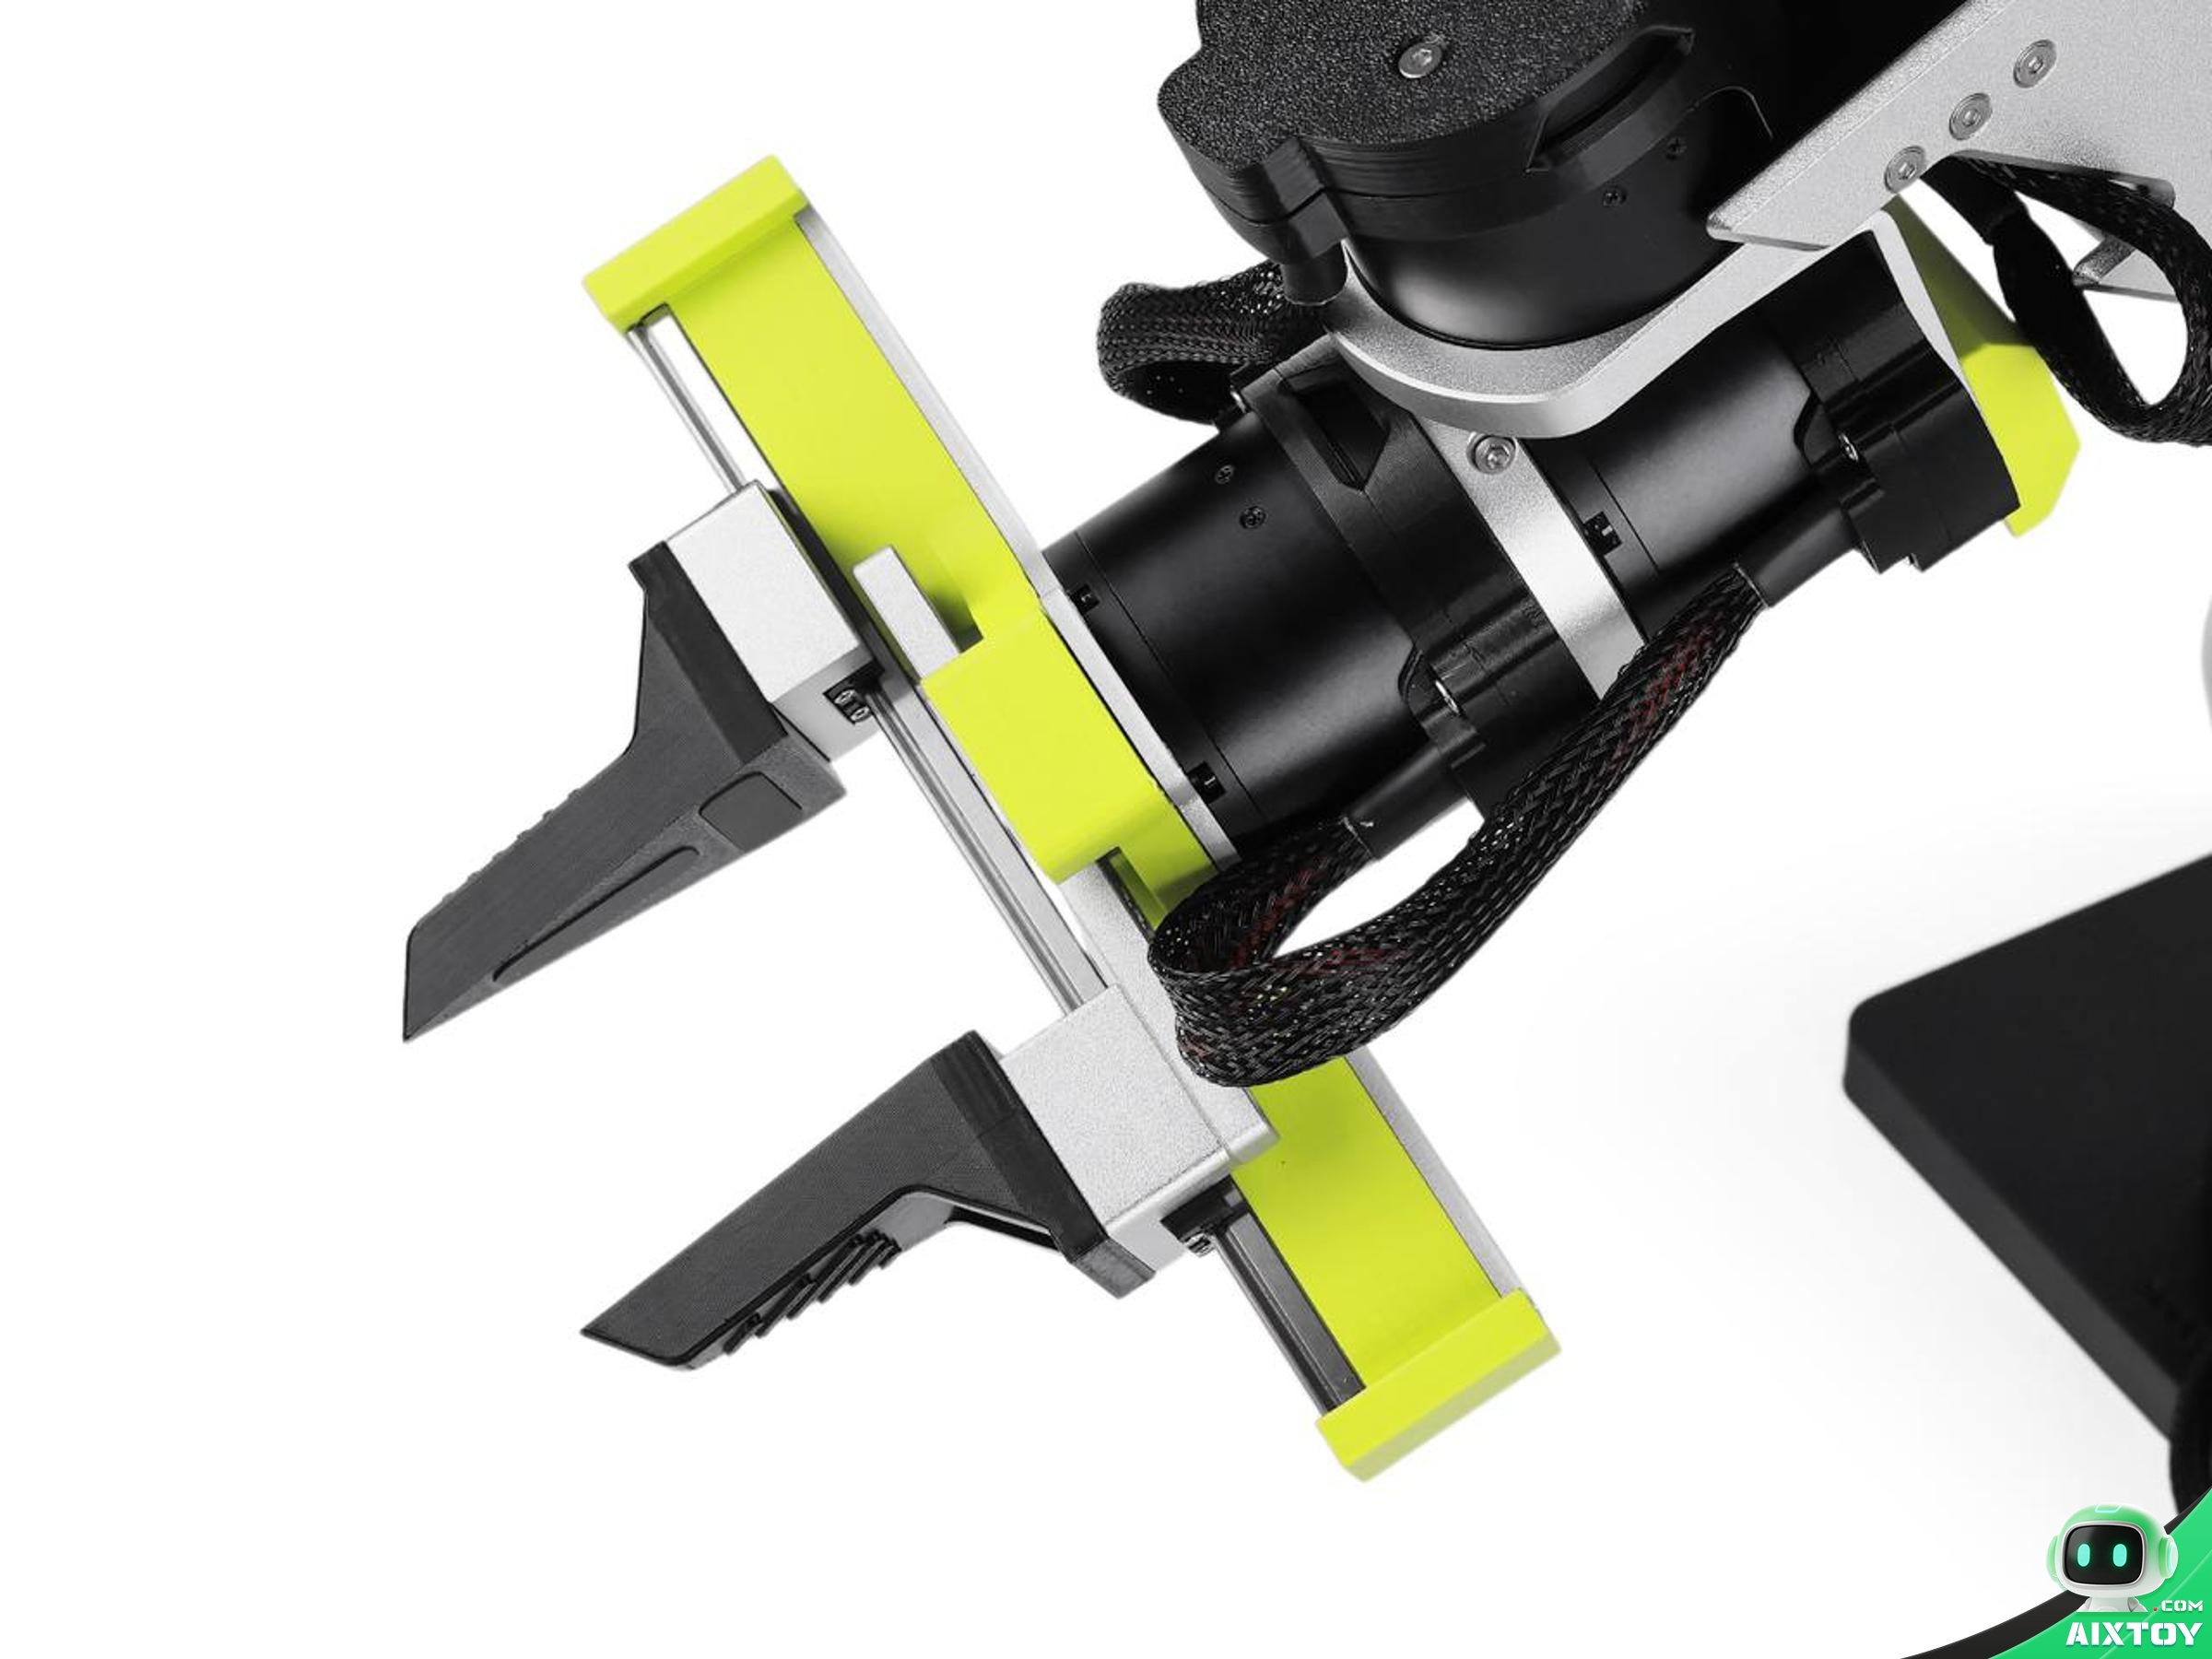
In community discussion, a full set of parts (unassembled) lands around $1,200, while self-sourcing the parts to replicate one is reported around $820. Note that the DM documentation’s reference prices for 3D-printed (~$48) and metal (~$205) parts are only the local manufacturing cost — motors, wiring, power supply, bearings, and labor come on top.
Before you replicate: what the community has learned
Developers who have already finished a real build flag a few hard-earned caveats:
- The official open files differ from the official retail parts. It is best to attempt a full replication only after the official software and peripheral open files are complete. Seeed also states clearly that the published BOM is not the final shipping version — the shipping version adds optimizations in metal laser engraving, 3D-printed part substitution, and custom wiring.
- Mind the licenses. On May 11, 2026 the project switched the hardware license from CC BY-SA-NC to CERN-OHL-W-2.0; the software uses Apache-2.0. Verify each license term before commercial redistribution.
- Do not use a virtual machine for control. Seeed’s official Wiki explicitly notes that a VM’s performance has been verified insufficient for running the demo and can cause configuration issues — prefer a physical Ubuntu machine.
- Assembly needs care. The kit contains many near-identical screws and structural parts. Seeed strongly recommends an electric screwdriver set to 3–6 kgf·cm of torque to avoid stripping screws and ruining parts.
Core resources
Official core resources
- GitHub official repository (main entry): github.com/Seeed-Projects/reBot-DevArm
- Gitee mirror (faster in China): gitee.com/seeed-projects/reBot-DevArm
- Seeed Studio Wiki — Chinese tutorials hub: wiki.seeedstudio.com/cn/robotics_page
- B601-DM hardware open docs (STEP + BOM): hardware/reBot_B601_DM
- B601-RS hardware open docs: hardware/reBot_B601_RS
Software & AI integration
- LeRobot getting-started tutorial (Chinese): wiki.seeedstudio.com/cn/rebot_arm_b601_dm_lerobot
- LeRobot getting-started tutorial (English): wiki.seeedstudio.com/rebot_arm_b601_dm_lerobot
- GR00T N1.7 fine-tuning & Jetson Thor deployment: fine_tune_gr00t_n1.7_for_rebot_arm
- NVIDIA Isaac Sim integration (official blog): seeedstudio.com/blog — reBot × LeRobot v0.6.0
- Sim-to-Real VLA course (with NVIDIA): seeedstudio.com/blog — sim-to-real VLA pipeline
- Vision grasping demo repo (YOLO/OBB + RGB-D): github.com/Seeed-Projects/reBot-DevArm-Grasp
Community tutorials (Bilibili)
- Full 58-minute assembly guide: BV1zPdzBEE1R
- Motor ID writing & zero-point calibration: BV1H2drBtENA
- For the “replication pitfalls guide” and the remaining LeRobot / teleoperation / ROS2 / power-assembly tutorials, search the corresponding keywords on the site.
Purchase & kits
- B601-DM official purchase page (SeeedStudio): seeedstudio.com — reBot-Arm-B601-DM-Bundle
- B601-RS official purchase page (early-bird $1,499): seeedstudio.com — reBot-Arm-B601-RS Assembled Kit
- DM quick start (with kit comparison): wiki.seeedstudio.com/cn/rebot_b601_dm_getting_started
- Power adapter: sold separately by default — the kit does not include the adapter or C-clamp; search
24V 4.5A XT30in the Seeed store for a replacement.
Summary
The core value of reBot DevArm is the combination of hardware openness depth and ecosystem integration breadth. It is not merely an open-source six-axis arm — it is one of the first validated hardware platforms for the NVIDIA + Hugging Face embodied-AI stack.
For developers already familiar with platforms like Unitree or Tiangong, reBot DevArm offers a complete closed loop from simulation to hardware, from data collection to policy deployment — with the entire chain backed by official documentation and community tutorials.
If you are looking for a desktop platform that is fully reproducible, ecologically mature, and community-active for validating embodied-AI algorithms, reBot DevArm is one of the most serious options to evaluate today.
Ready to start? Take a look at the reBot Arm B601-RS Open-Source 6-Axis Robotic Arm in the AIXTOY store — the newer reBot platform, shipped with high-precision joints, open hardware files and full ROS2 support. You can also browse our other open-source robot coverage and the four open-source desktop robot projects comparison.
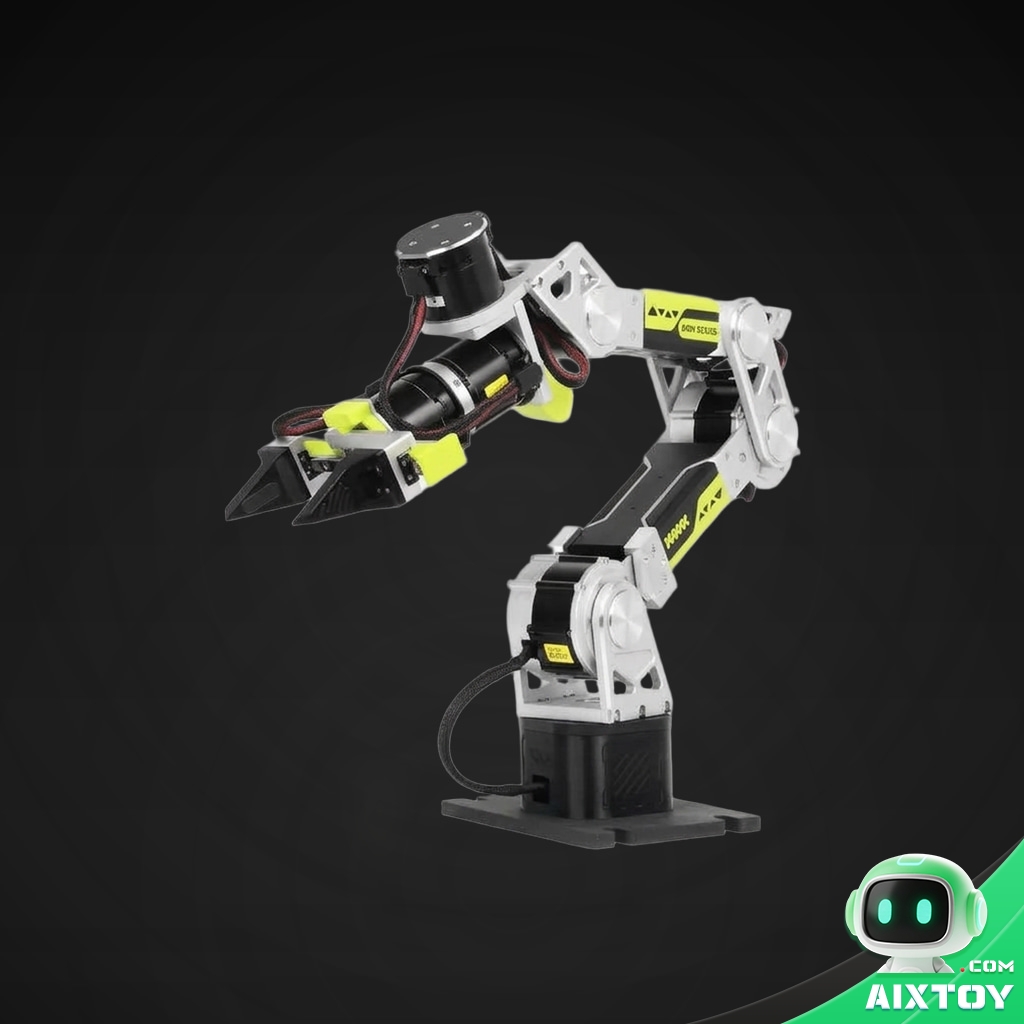
reBot Arm B601-RS Open-Source 6-Axis Robotic Arm
From $1,551.99
The open-source 6-axis reBot Arm B601-RS — the successor platform in the same reBot family, with high-precision joints, published hardware files and a clean path from teleoperation to policy deployment.
Tags:reBot Robot Arm Open-Source Robot Seeed Studio NVIDIA GR00T LeRobot VLA DIY Robot Robotics ROS2