
No products added!

Price range: 299.99$ through 379.99$

12 V 5 A DC

Mostly Assembled

LeRobot + K230
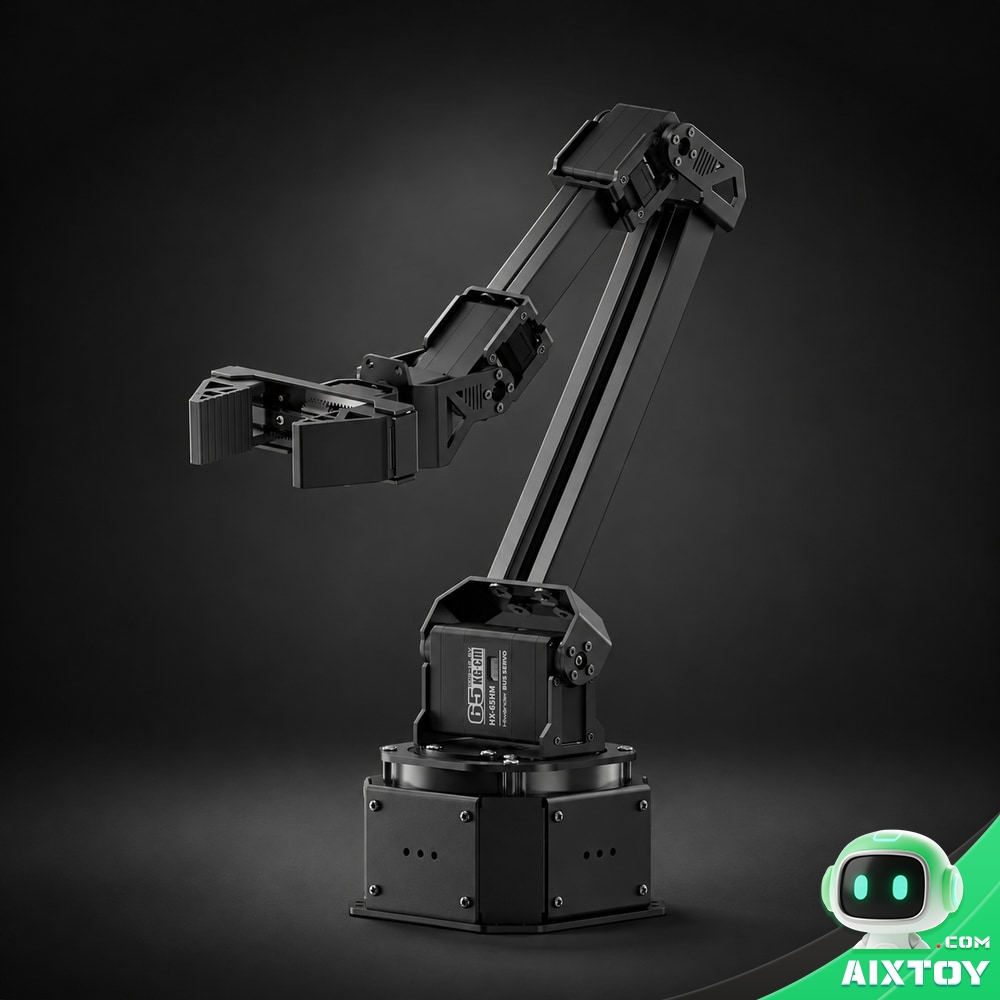
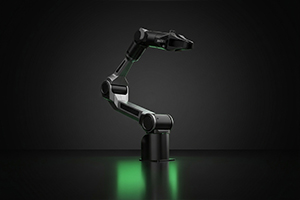
NexArm is an open-source six-axis robotic arm built by Hiwonder for embodied AI and VLA (Vision-Language-Action) work. It is not a demo arm with a friendly face bolted on: it is a full pipeline — drag the leader arm to demonstrate, record synchronised vision and joint data, train a policy on your own GPU, then let the follower arm repeat the task on its own.
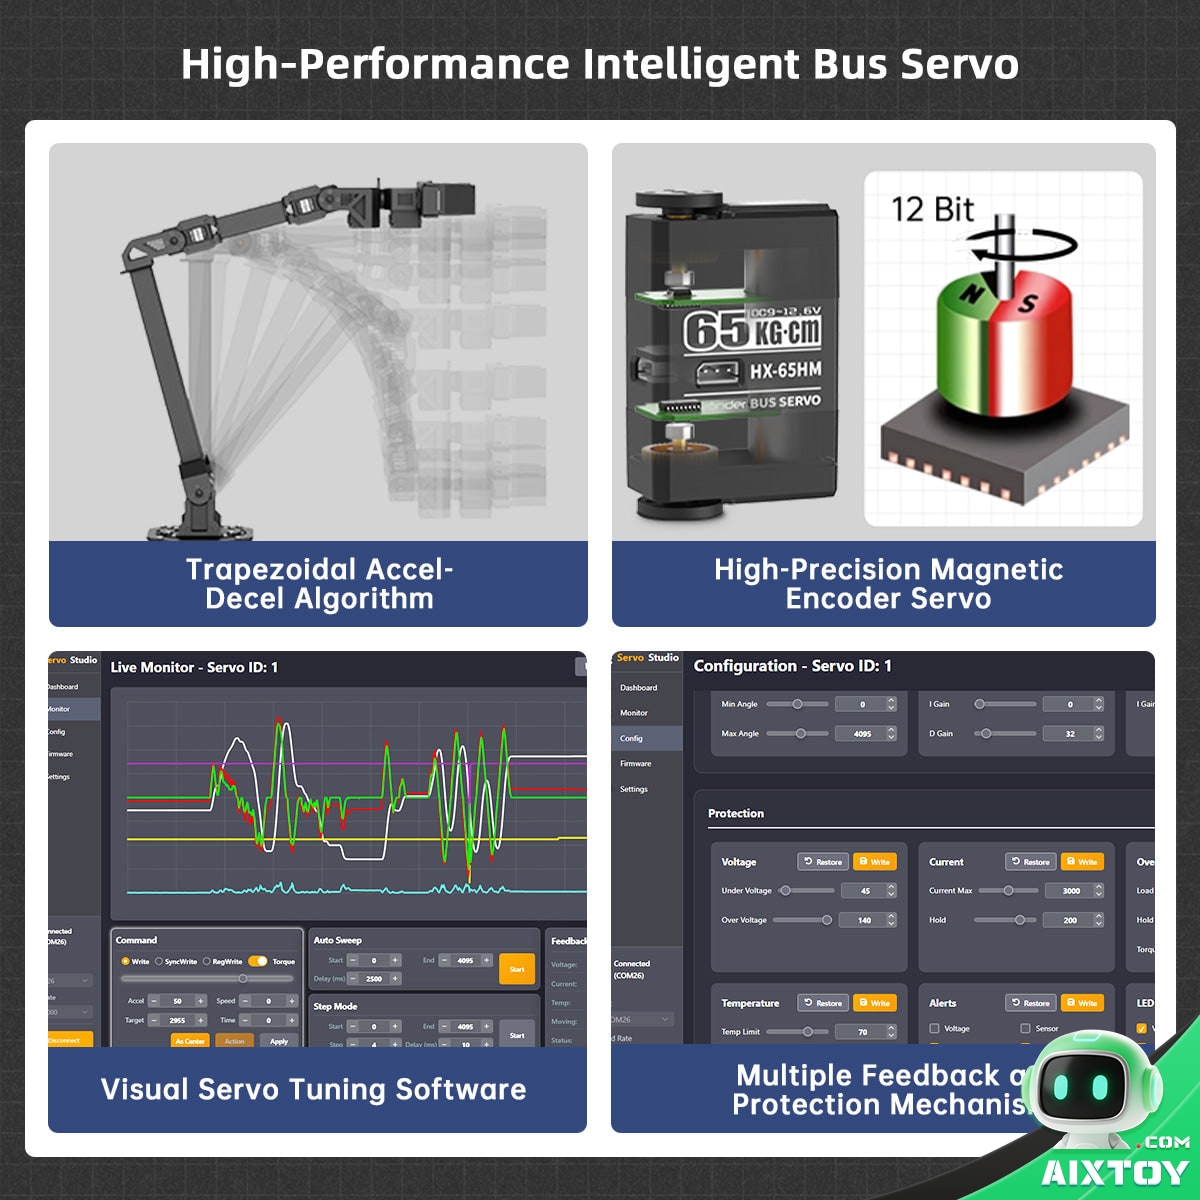
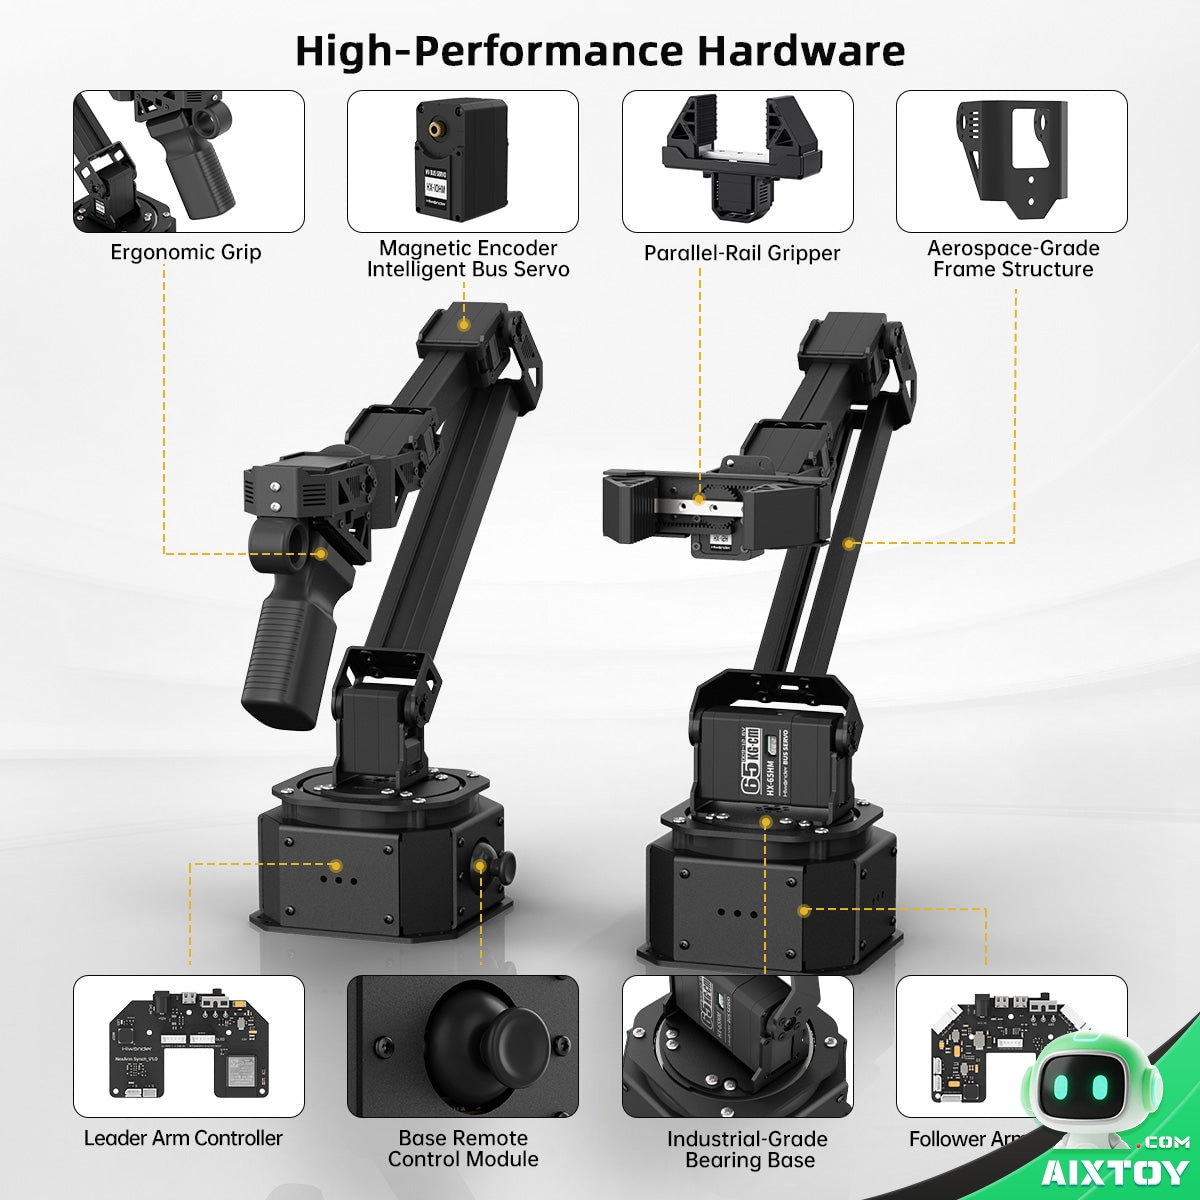
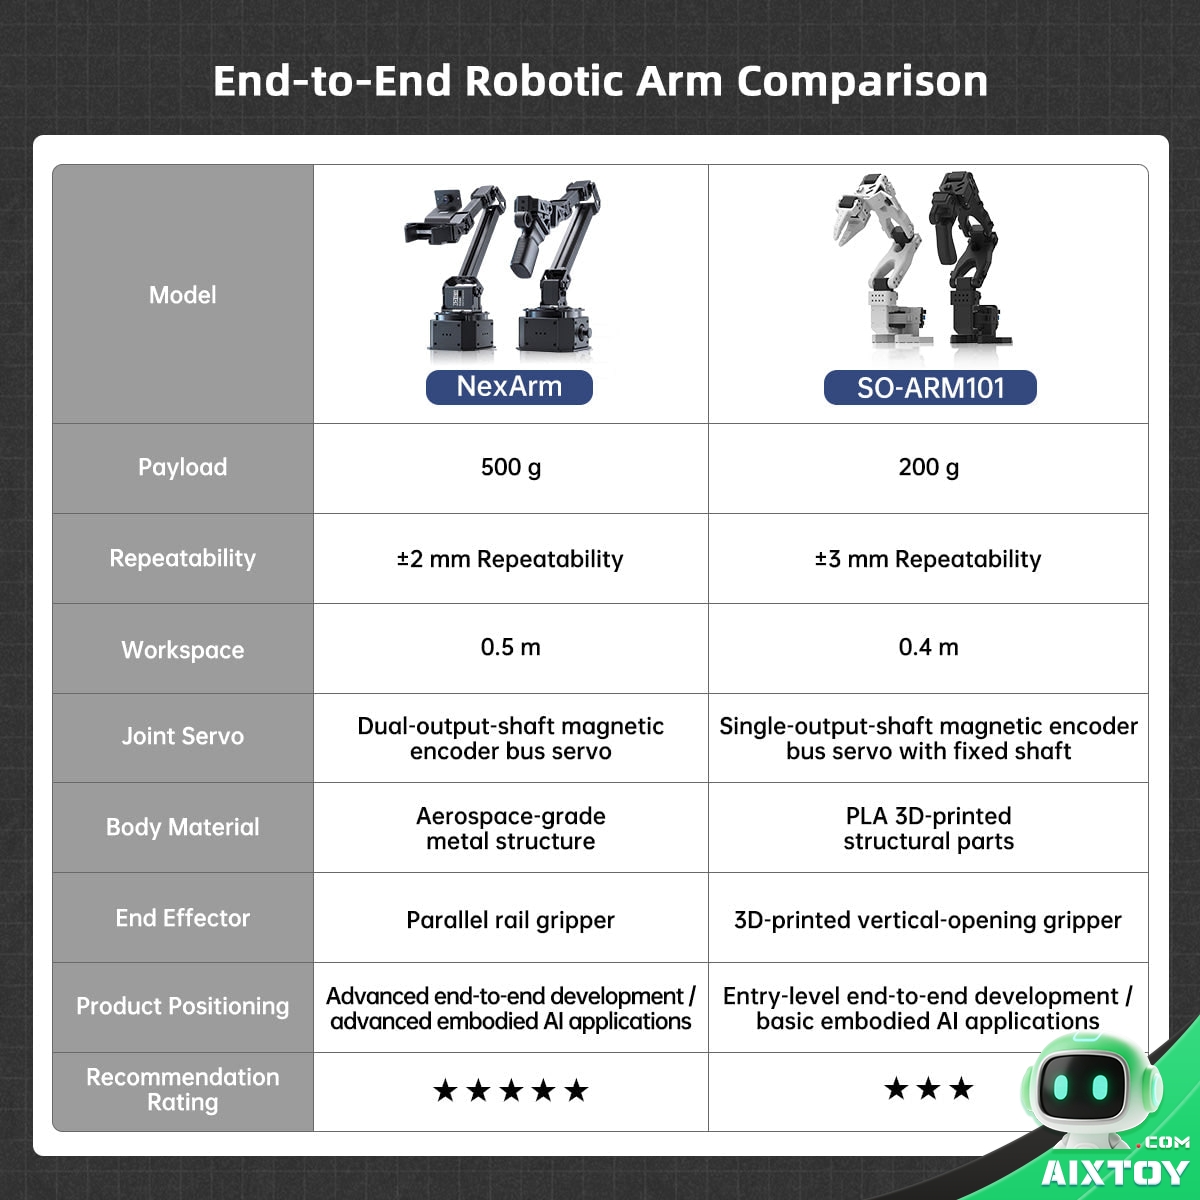
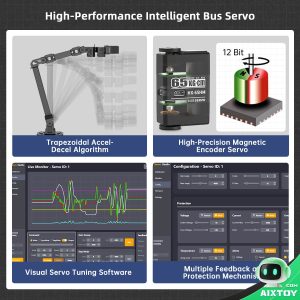
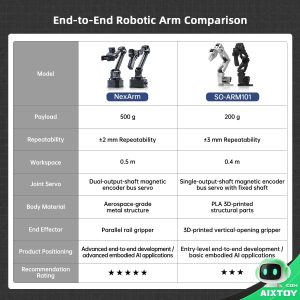
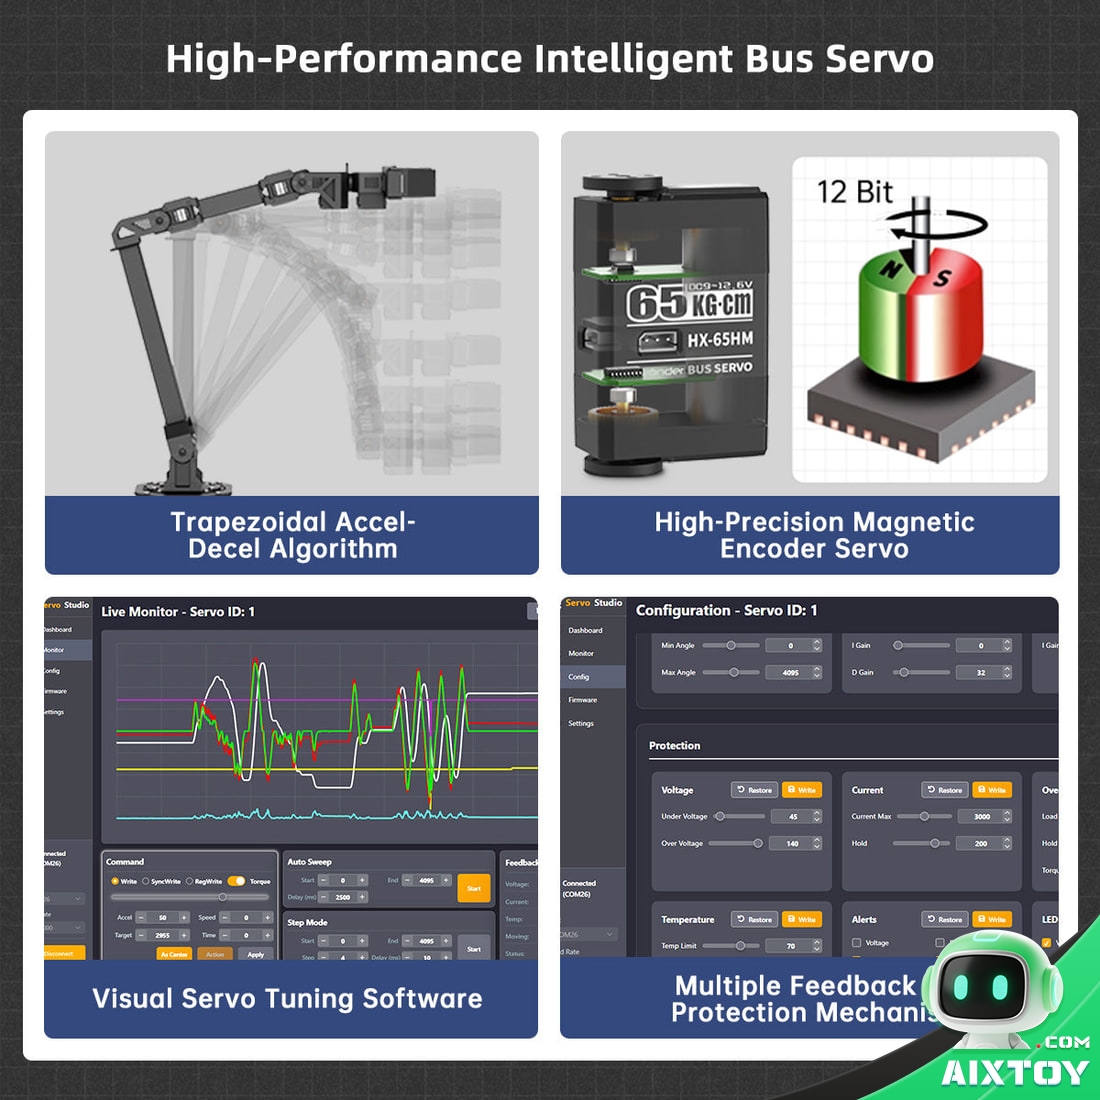
The base joints run dual-output-shaft magnetic encoder bus servos rated at 65 kg·cm, delivering a 500 mm working radius and a hemisphere of roughly one metre across. The 12-bit magnetic encoders are contactless, so there is no brush wear, and every frame returns a true joint angle — exactly the raw signal imitation learning needs. Trapezoidal acceleration and curve interpolation keep the motion smooth instead of the usual servo stutter, with ±2 mm repeatability.
An ESP32 + AT32 dual-chip architecture splits the work: the upper chip handles communication and decisions, the lower one solves inverse kinematics and drives the servos in real time. Because inverse kinematics is on board, you can command a Cartesian target and the arm works out the joint angles itself.
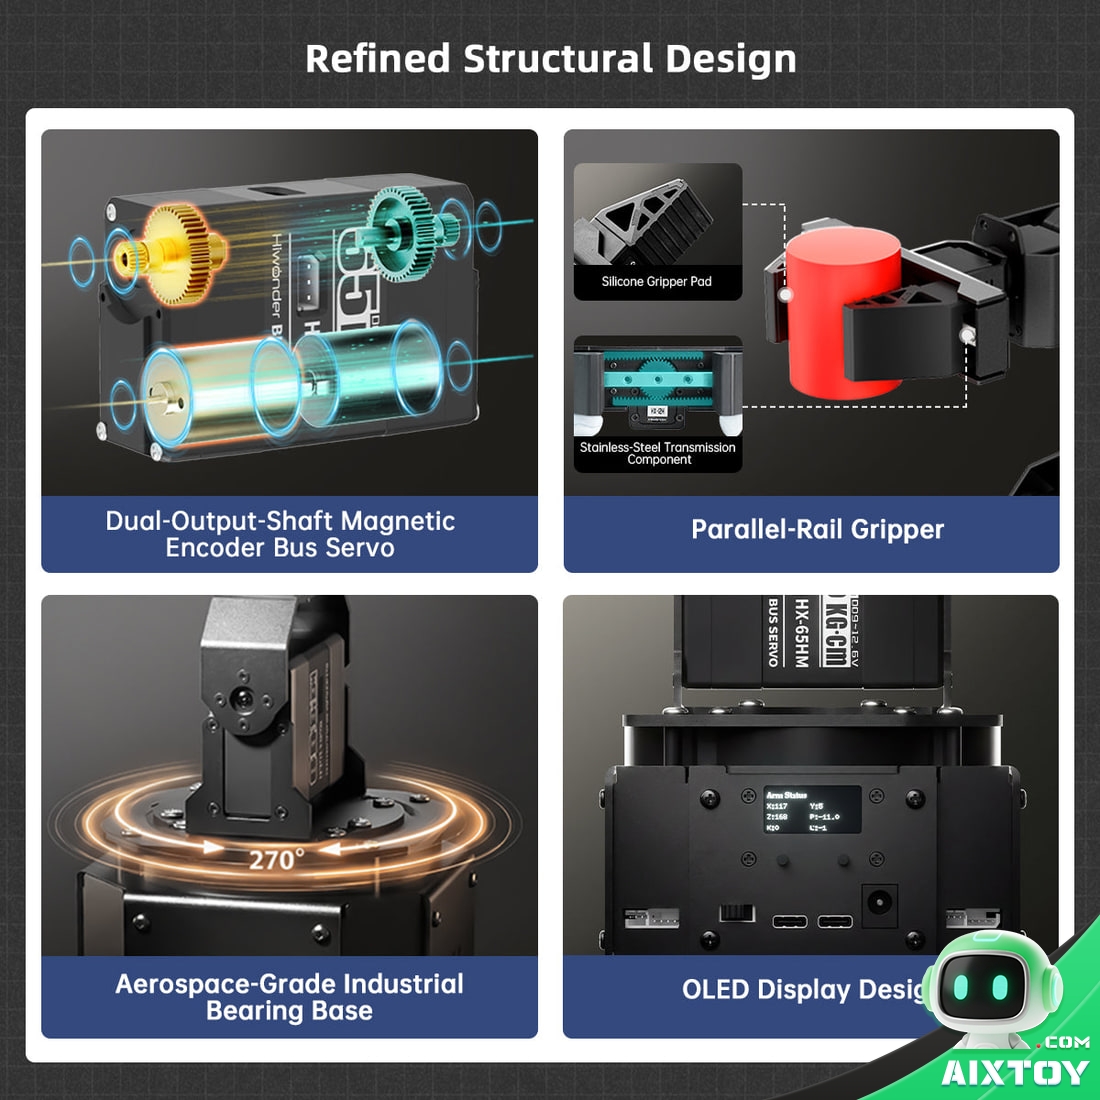
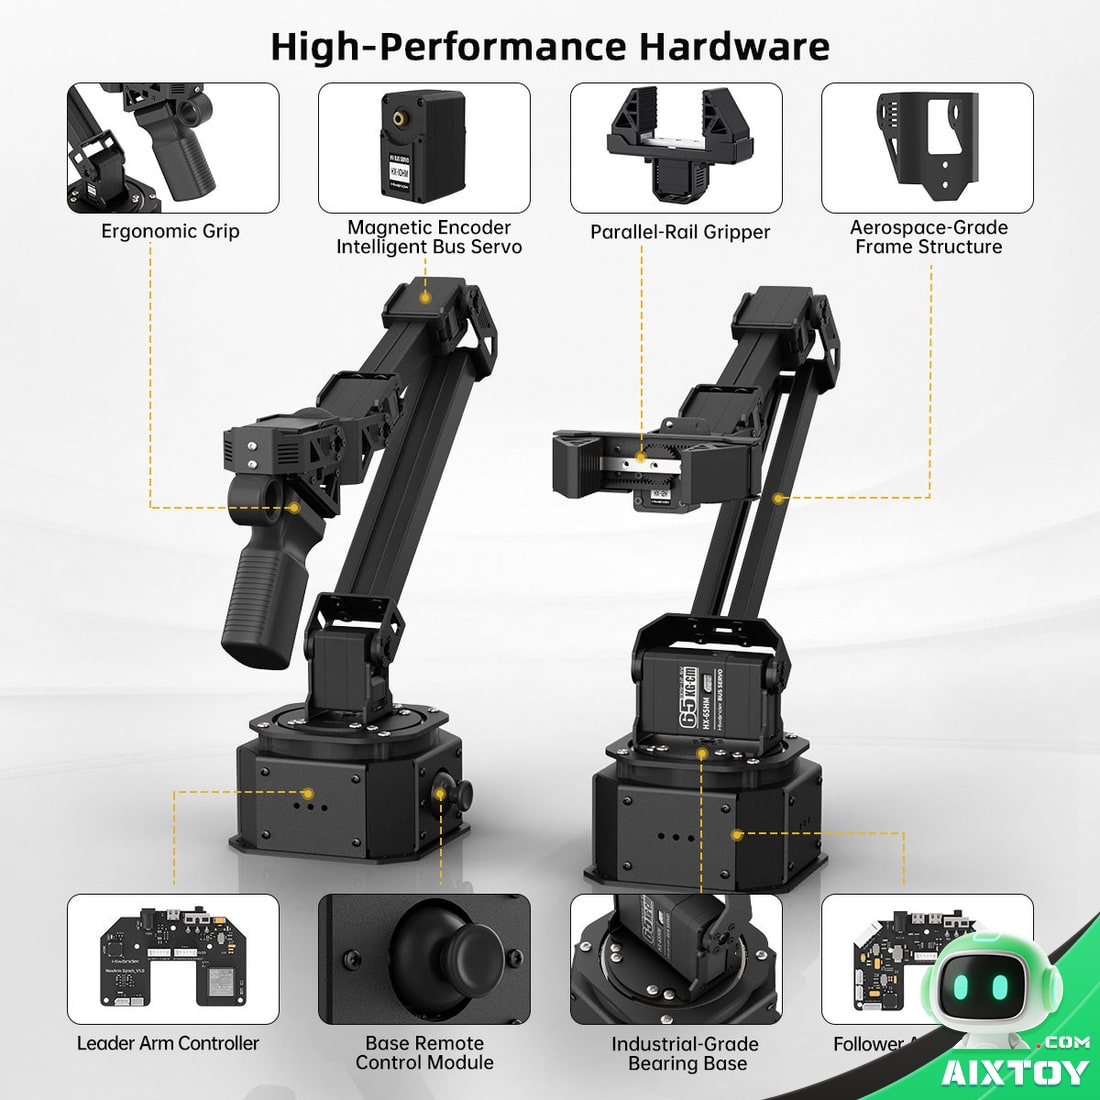
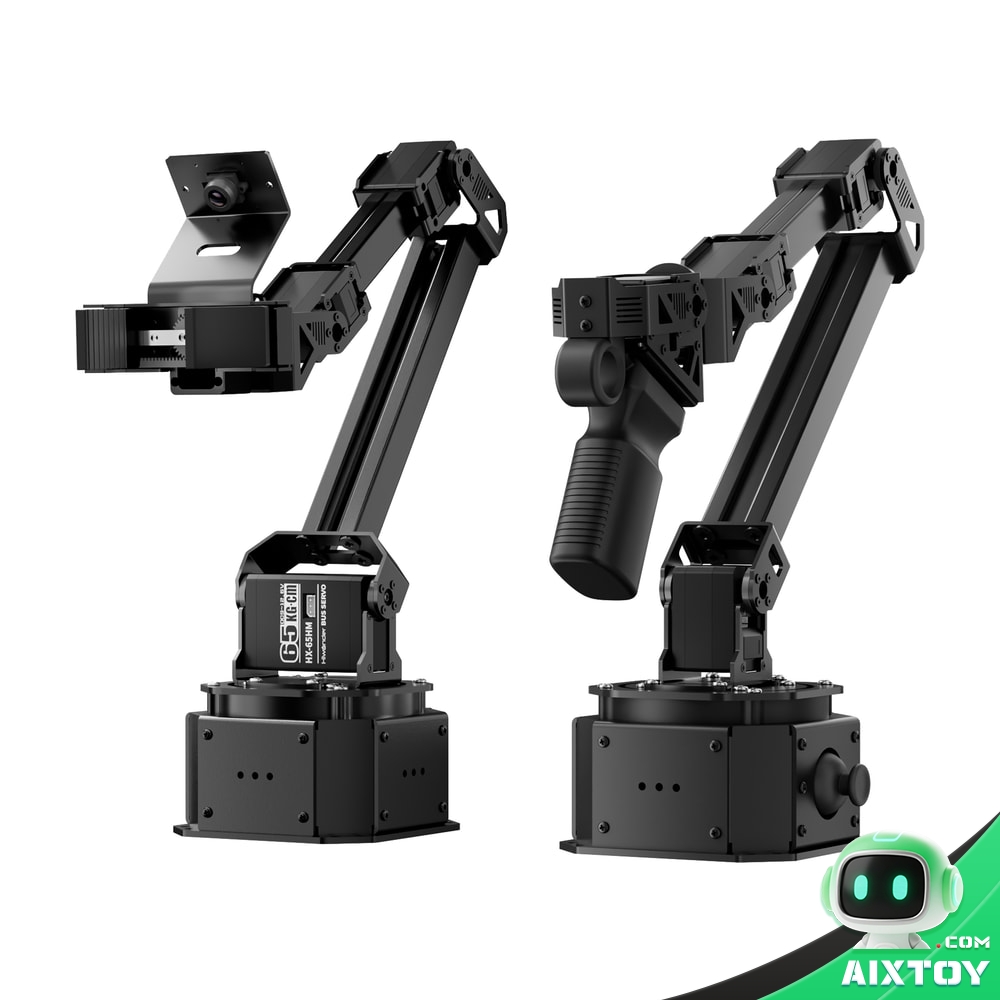
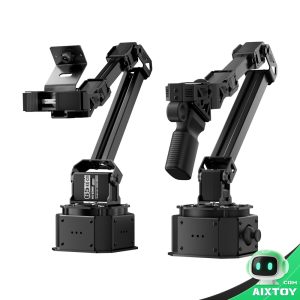
Teleoperation uses a classic leader-follower pair. The leader arm uses a 1:147 gear ratio for high-frequency demonstration capture; the follower uses 1:345 for positioning stability. The two arms are geared and mounted so their mirrored motion stays correct, and two cameras — mounted at the gripper and looking over the workspace — record the vision-action pairs that make the resulting dataset usable.
Recordings push straight to the Hugging Face Hub, and training runs against the LeRobot framework with policies such as ACT, Diffusion Policy and Pi0. Because it is an action-chunking approach, the trained policy predicts ahead in blocks rather than frame by frame — which is why deployment can run at a usable rate on an ordinary CPU once training is done on a GPU.
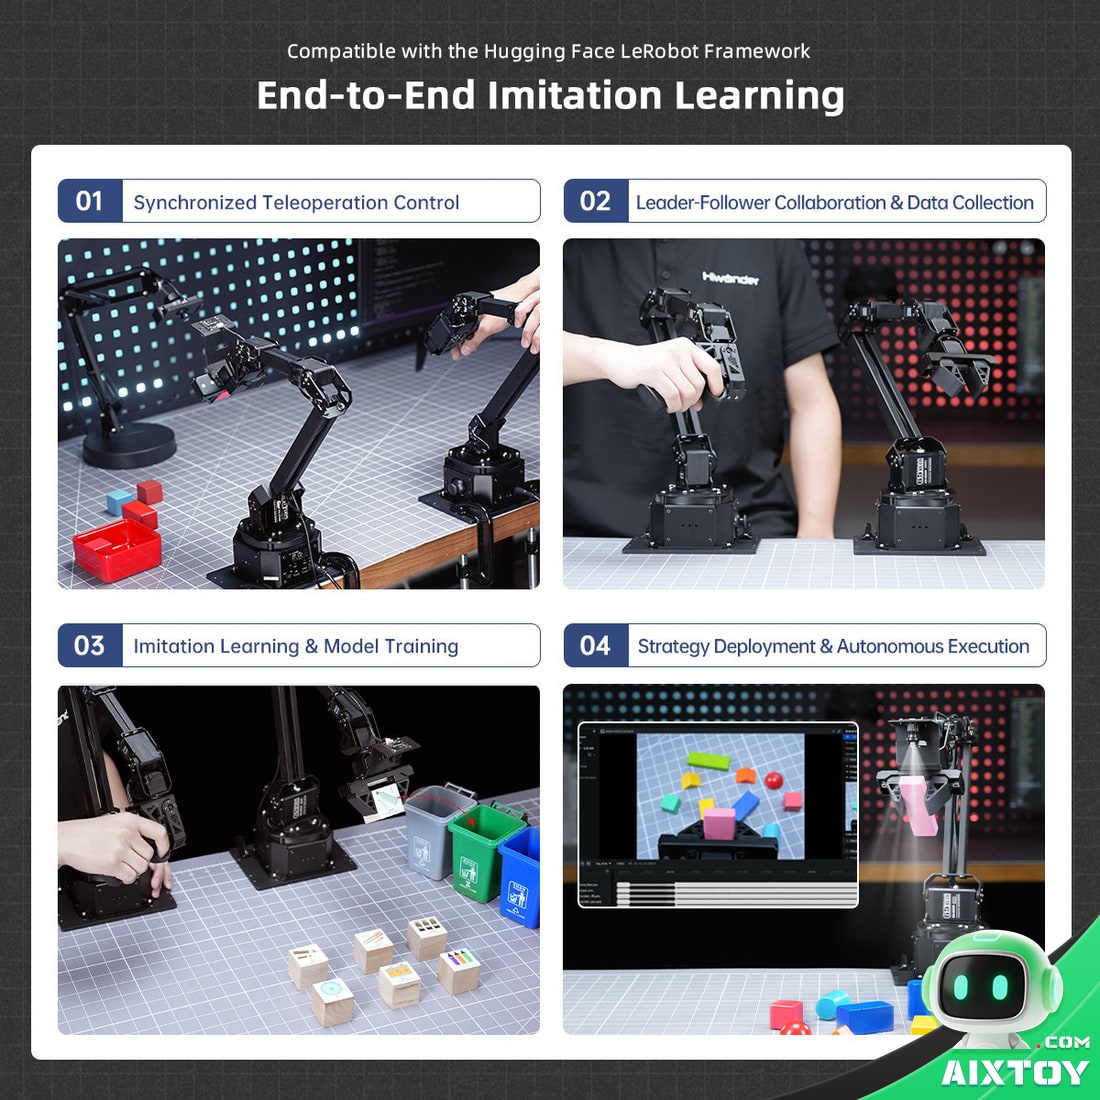
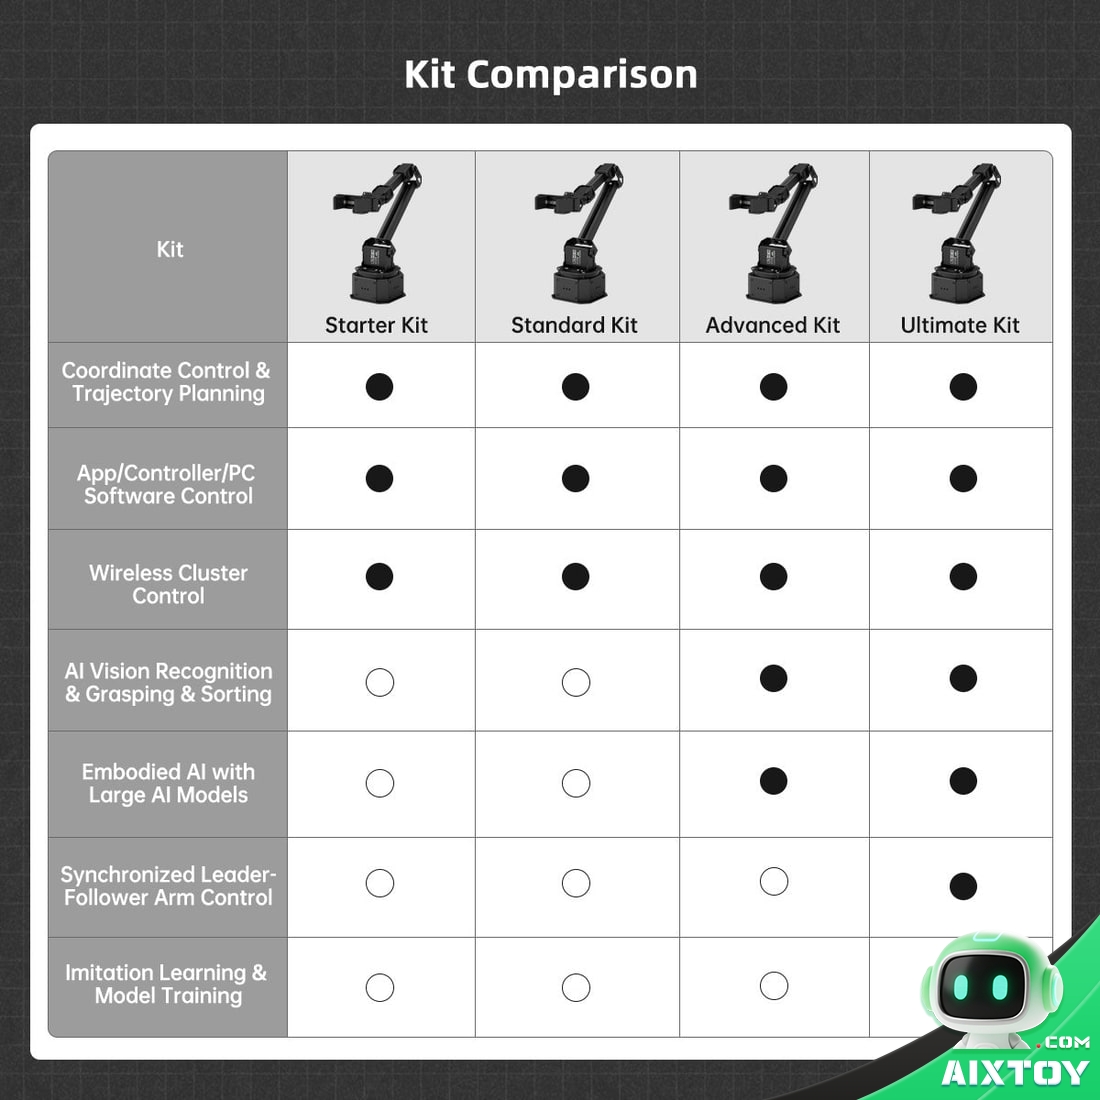
Each kit ships with one arm — the follower, the unit fitted with the parallel-rail gripper. The leader arm, the handle version you drag by hand, is not included and is available as a separate add-on. So the leader–follower loop described above takes one of each, while single-arm work such as vision-guided sorting or standalone pick-and-place runs on the follower on its own.
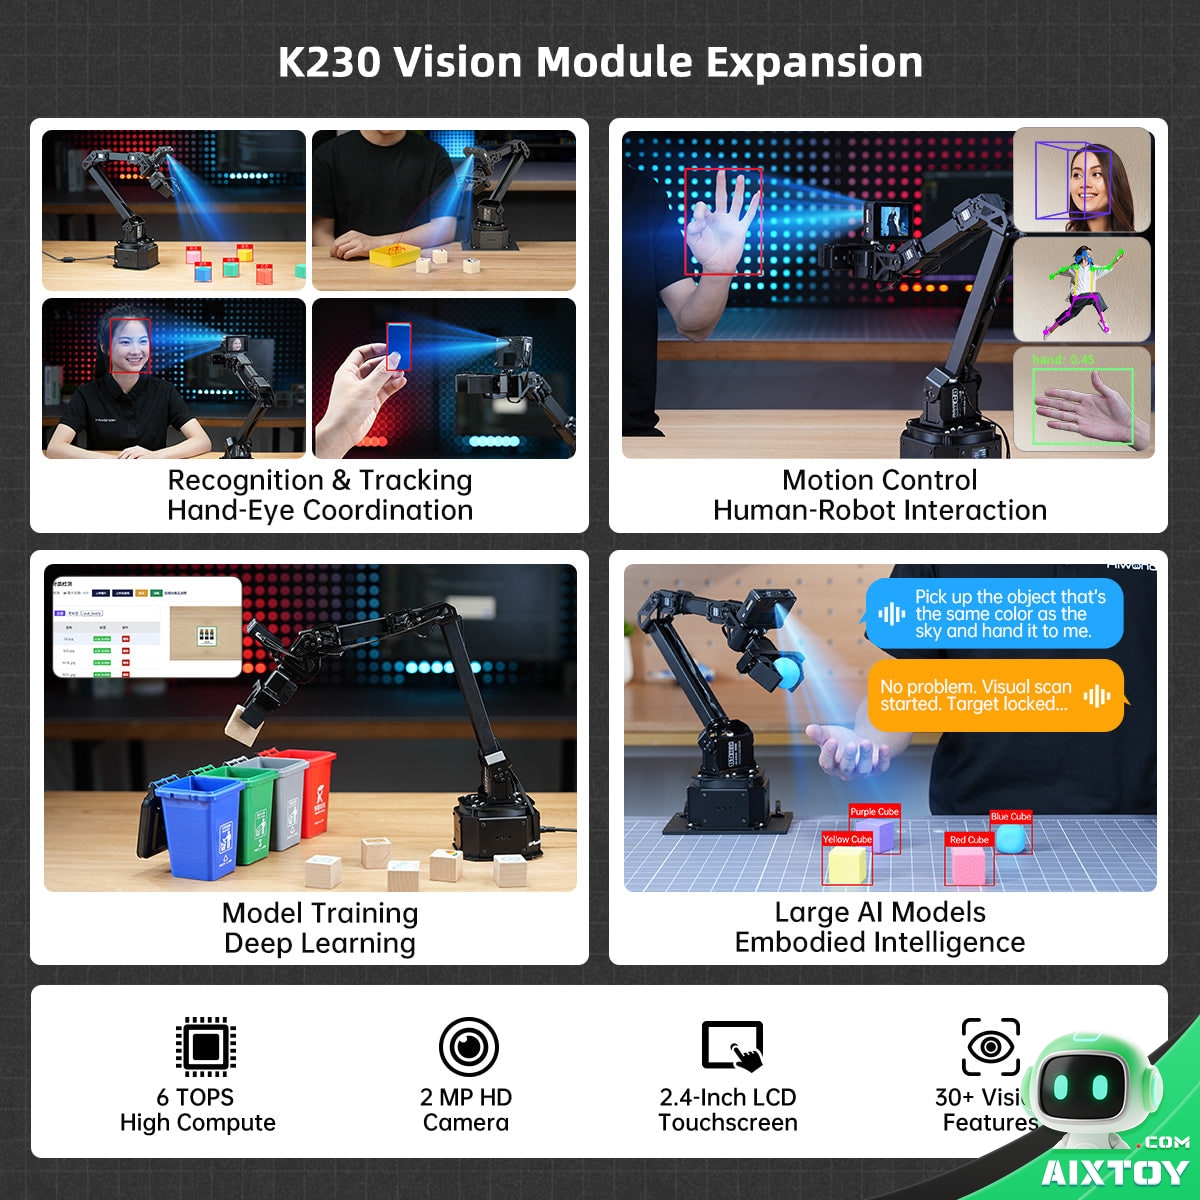
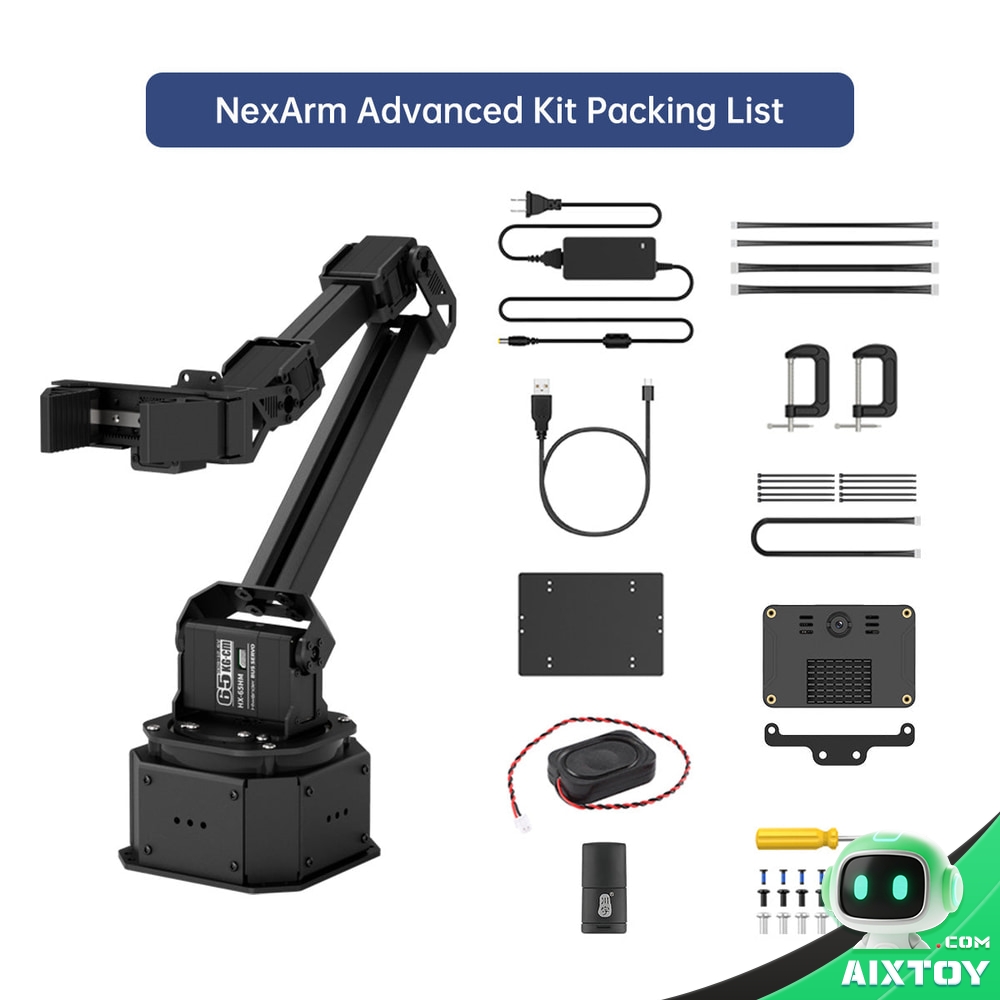
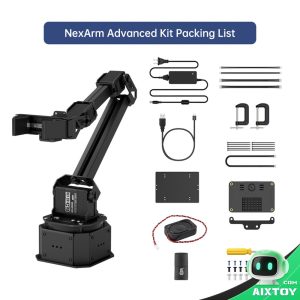
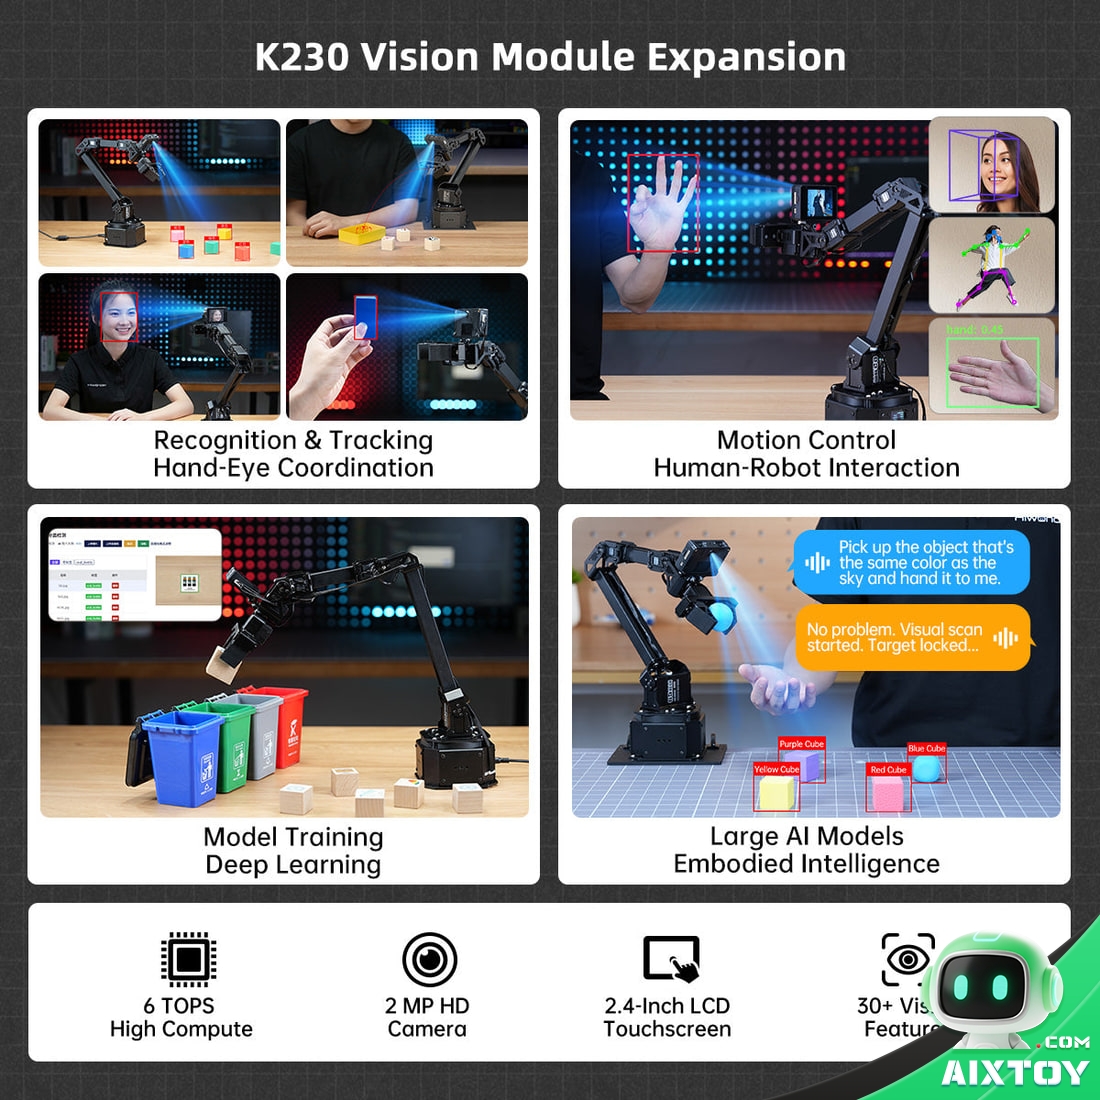
Standard Kit and Advanced Kit contain the same arm; they differ on vision and accessories. The Advanced Kit adds the K230 AI vision module, its mounting bracket, a card reader, a speaker, a 1,000 mm module cable and ten cable ties.
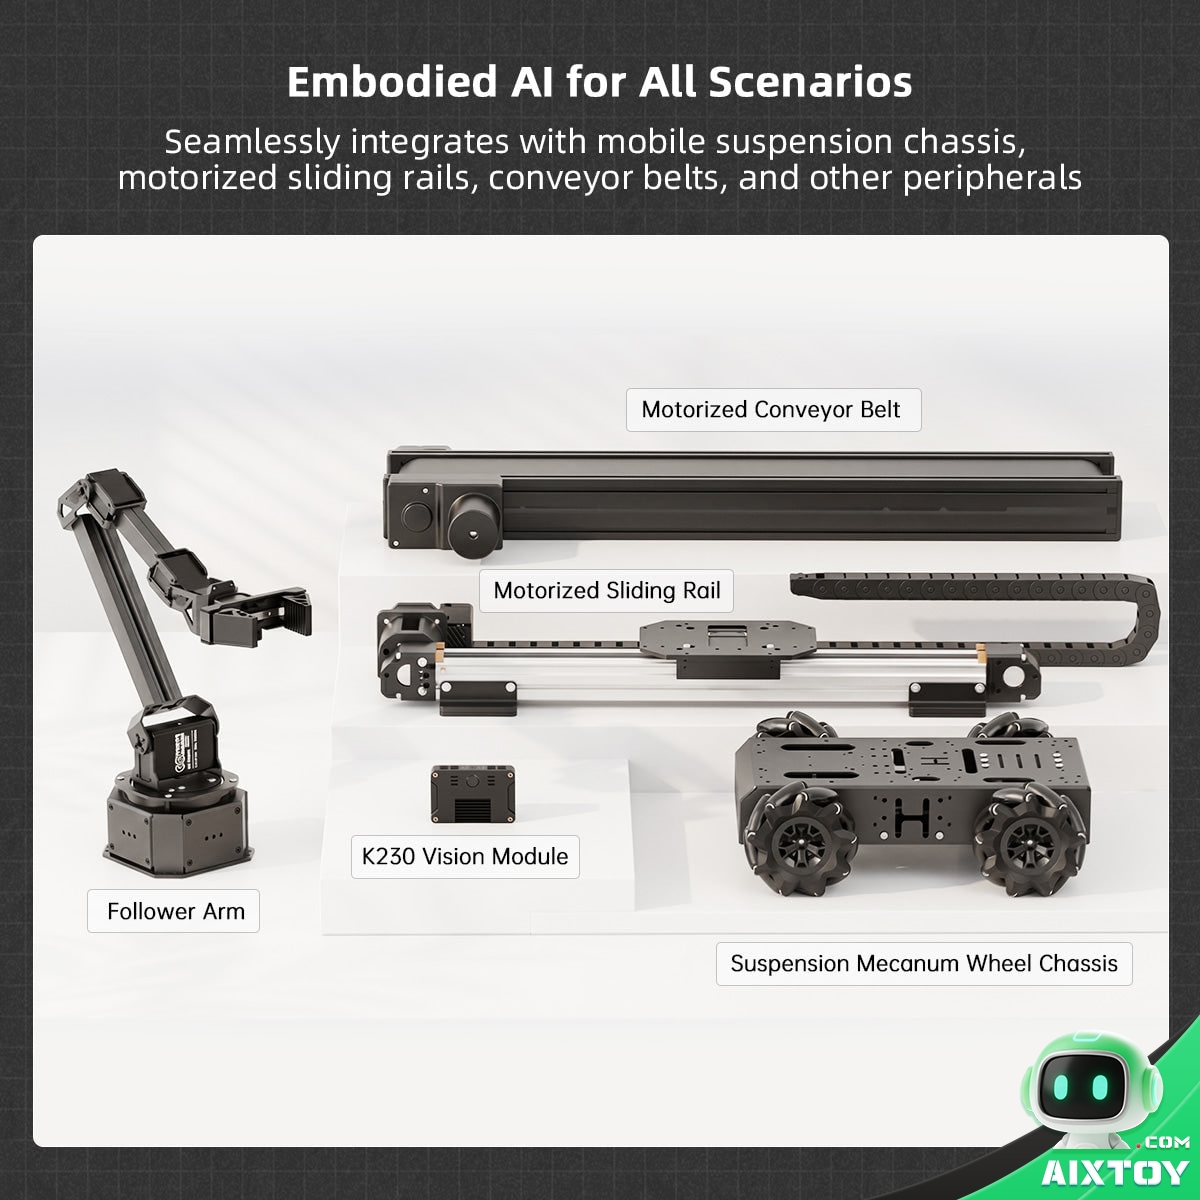
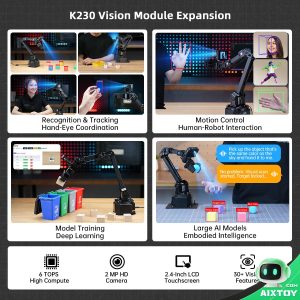
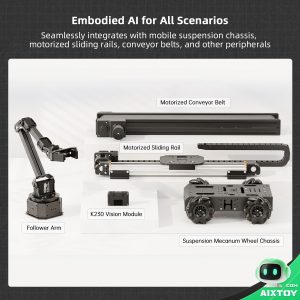
The optional K230 module adds 6 TOPS of vision compute with more than 30 built-in functions — colour, object, face and gesture recognition, sorting, tracking and hand-eye coordinated grasping — without tethering the arm to a PC. Control is just as broad: the companion app moves each joint independently, the leader arm can be dragged offline for teaching, a wireless controller pairs one-to-one for low-latency operation, and ESP-NOW supports unicast, multicast and broadcast so several arms can work as a cluster. The arm also mounts on a mobile chassis, a sliding rail or a conveyor belt.
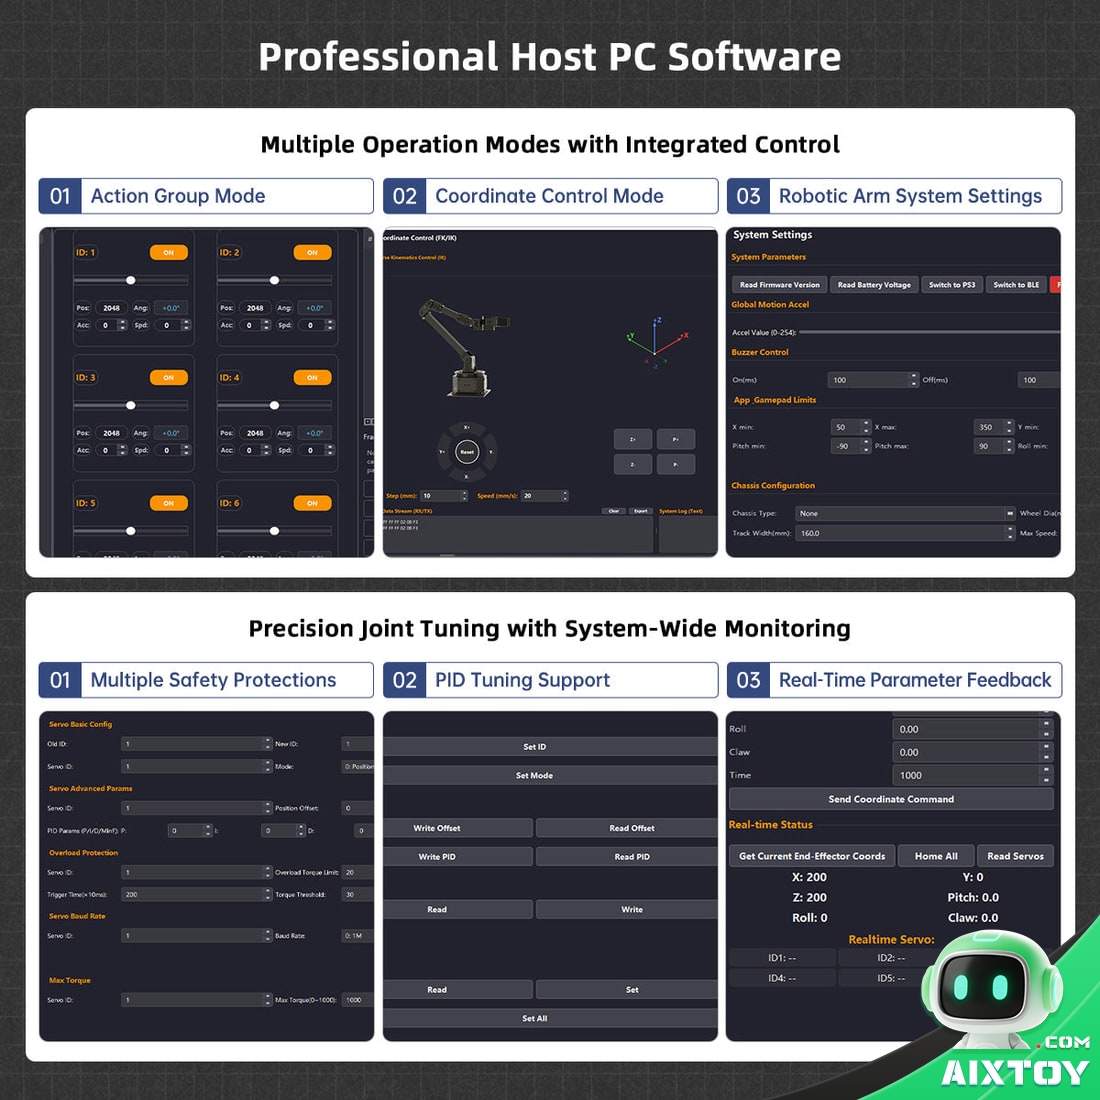
Code, schematics, PC software and structured tutorials are open, and the toolchain is cross-platform across Windows, Linux and macOS with the Arduino IDE.
| Brand | Hiwonder |
| Axes | 6 |
| Payload | 500 g |
| Reach / workspace | 500 mm |
| Repeatability | ±2 mm |
| Material | Metal frame (industrial / aerospace-grade structure) |
| Kit contents | 1 × follower arm + accessories (leader arm sold separately) |
| Dimensions | Leader arm 111 × 216 × 619 mm; follower arm 111 × 111 × 614 mm |
| Weight | Leader arm 1.2 kg; follower arm 1.3 kg |
| Servos (leader) | HX-10HM × 5 + HX-12H × 1 |
| Servos (follower) | HX-12H × 2 + HX-30HM × 3 + HX-65HM × 1 |
| Servo spec | 12-bit magnetic encoder bus servo, 65 kg·cm at base joints, 1 Mbps serial bus |
| Controller | ESP32 + AT32 dual-chip |
| AI vision (Advanced Kit) | K230 module, 6 TOPS, 30+ vision functions |
| Cameras | Gripper first-person view + global third-person view |
| Power | 12 V 5 A DC (5.5 × 2.5 mm) |
| OS | Windows / Linux / macOS |
| Control | USB serial / Bluetooth / Wi-Fi, app, PS3 wireless controller, ESP-NOW cluster; Arduino IDE |
| Packaging | Standard Kit 3.2 kg; Advanced Kit 3.3 kg (345 × 158 × 220 mm) |
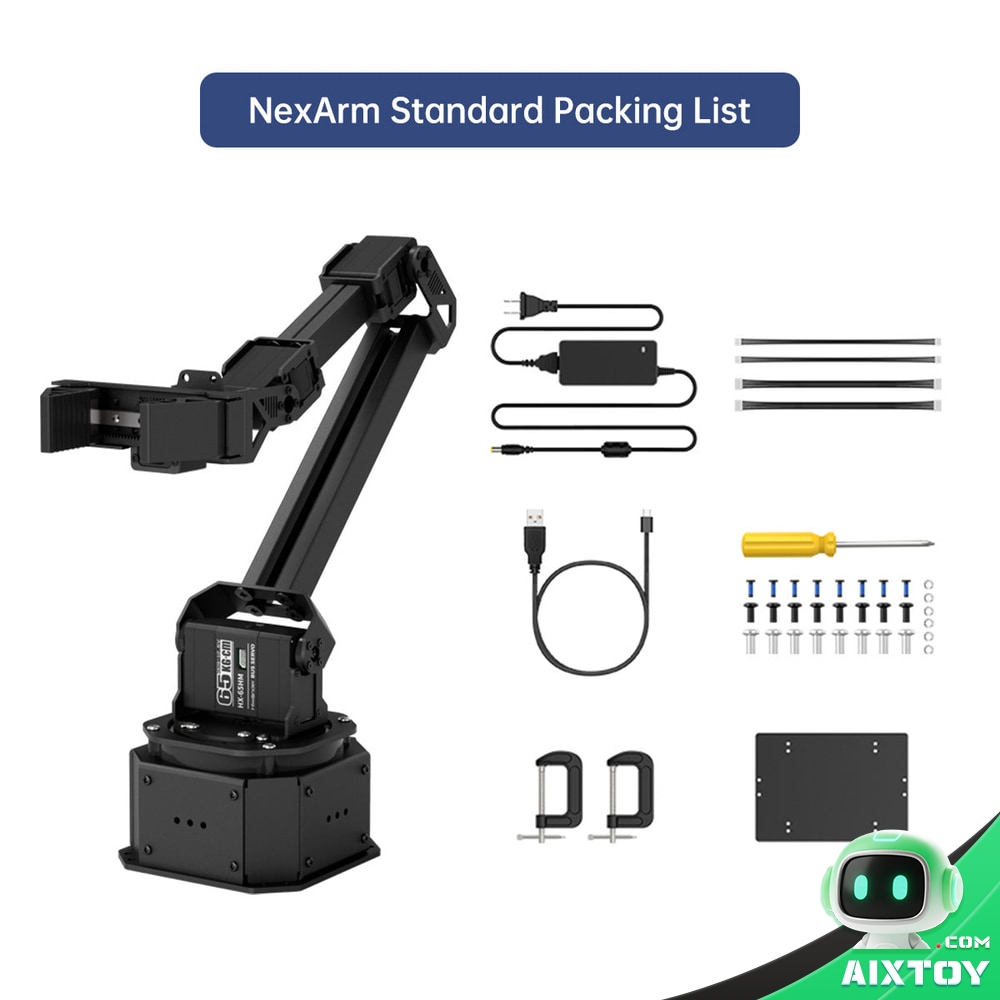
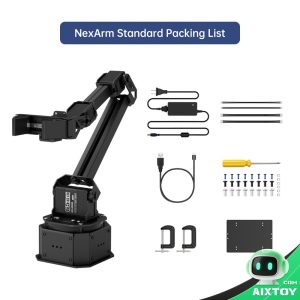
What differs between the two kits. Standard Kit ships the arm with the 12 V adapter, cables, screwdriver, two G-clamps, screw pack and adapter base plate — you mount it on a bench and start teleoperating. Advanced Kit adds the K230 AI vision module, its mounting bracket, a card reader, a speaker, a 1,000 mm module cable and cable ties, which is what you want for vision-guided sorting, tracking and hand-eye coordinated grasping.
Training needs a GPU; the official starting point is an RTX 3090-class card, though you can teleoperate and collect data without one, and rent GPU time for the training step.
NexArm is an open-source project by Hiwonder; code and schematics are published by the manufacturer. Requires assembly of the base plate for the Standard and Advanced kits.
| Weight | 3200 g |
|---|---|
| Dimensions | 34.5 × 15.8 × 22 cm |
| Package | Standard Kit, Advanced Kit |
You must be logged in to post a review.

Rechargeable
Ready
Voice AI
Voice Control
Remote RC
AI Program
Rechargeable
Ready
Voice AI

Rechargeable
Ready
Voice AI
Rechargeable
Ready
Voice AI
Wholesale pricing is available to approved wholesale accounts only.


Reviews
There are no reviews yet.